An affine space has no origin, so it has no subspaces
in the sense of Chapter 1: a subspace must contain , and there is no
. What it
has instead are its flats — the lines,
planes, and hyperplanes that sit inside it. This section
defines them, settles when two of them meet and how big
the smallest flat containing both is, puts coordinates
on an affine space using points rather than vectors, and shows that
in the
flats are exactly the solution sets of linear systems.
The join formula has two cases, and the second one is
where affine geometry parts company with linear
algebra.
Throughout,
is an affine space over a field with direction space
(Definition 22.1.1), and
from the dimension formula onward is
finite, except where a statement says otherwise.
Flats
A subset of
deserves to be called flat when it is an affine space in
its own right, using the same difference map. By Definition 22.1.2 there
is only one thing to require.
A flat is a nonempty set of points closed under
taking affine combinations.
Definition
22.2.1 (Flat)
A subset is a flat, or an
affine subspace of , if it is
nonempty and contains every affine
combination of its own points: whenever
, and
satisfy , the point lies
in .
The requirement that be nonempty is a
convention, and it is the useful one: a flat is going to
have a direction space and a dimension, and the empty
set has neither. Intersections of flats may of course be
empty, and we will say so each time.
Proposition
22.2.1 (Flats Are the Cosets)
Let be nonempty. Then is a flat if and only
if there are and a subspace of with . In that case:
- (a) is determined by alone; it is written
and called
the direction space of .
- (b) for
every , and ,
with the difference map of restricted to it, is
an affine space with direction space .
The dimension of is . A flat of dimension is a single
point, one of dimension is a
line, one of dimension is a
plane, and, when is finite,
one of dimension is a hyperplane of .
Idea. One direction is a
computation with origin . For the other, fix
and let
be the set of
displacements from to points of ; the three subspace
axioms come from three affine combinations, with weight
lists ,
and .
Proof. Let with a subspace, and let
with . Computing
the affine combination with origin (Definition 22.1.2), since
is closed under linear combinations. And is nonempty.
Let be a flat,
fix and put
. Then . If and , the point
lies in and equals when
computed with origin , so . If
also , the point lies in (weights ) and equals
, so . By Theorem 1.2.1, is a subspace, and
by
construction.
(a) Let . Then
by Chasles, since
is closed under negation and addition; so . Conversely each is for
some , and
. Hence the
two sets are equal, and the right-hand side mentions
only .
(b) Let . For we have by (a), so ;
and for , writing with , the point
is the
affine combination of points of , hence lies in . So . Finally
the restricted difference map takes values in by (a), Chasles
is inherited, and for fixed the map is a bijection , being the
restriction of the bijection of (AS2) to . So (AS1)
and (AS2) hold and is an affine space with
direction space .
Over , with
, a flat is
exactly Chapter 18’s affine subspace of (Definition 18.1.5 (b)),
and the two dimensions agree: Chapter 18 also reads the
subspace off the coset as the set of differences.
Chapter 5’s affine hyperplane (the
paragraph before Proposition 5.6.4) is the
case
in . A
one-point set is a flat, and is a flat:
the two degenerate cases.
A nonexample, by minimal change. A
line is a flat; the union of two lines is not. Let , the union of the two coordinate axes. It is
nonempty, and it contains every affine combination of
points taken from one axis, each axis being a flat. But
Definition 22.2.1 asks
for all of them: the points and lie in , the weights of add
up to , and has . So
the closure clause fails for one pair of points, and
is not a coset of
a subspace, although it is a union of two of them.
Proposition
22.2.2 (Intersections of Flats)
Let be a nonempty family of flats of and put .
If ,
then is a flat
and .
Proof. Suppose and fix
. If and
,
then the point lies in each , because each is a flat containing
all the ; so it
lies in . Hence
is a flat. By Proposition 22.2.1 (b),
for each and
, so
where the middle equality holds because is injective (AS2).
Since itself
is a flat containing every subset, the following is well
defined.
Definition
22.2.2 (Join of Flats)
Let be
flats of . Their
join is the intersection of all flats of containing .
The intersection contains , so it is nonempty, and
it is a flat by Proposition 22.2.2: is the
smallest flat containing both. A single
point is a flat,
and we write , for joins in which a one-point flat appears. This is
the affine analogue of , and Chapter 18’s affine hull is the same
construction over (Proposition 18.1.4).
Parallelism is what an affine space has and a vector
space does not notice.
Definition
22.2.3 (Parallel Flats)
Two flats
of are
parallel, written , if .
Proposition
22.2.3 (Parallelism)
Parallelism is an equivalence relation on the set of
flats of . Two
parallel flats are either equal or disjoint, and each
equivalence class consists of the flats , , for one fixed
subspace .
Proof. Equality of direction spaces
is an equivalence relation, so is one. Let
with
common direction ,
and suppose . Then by Proposition 22.2.1 (b).
So and are equal or disjoint.
Finally, the flats with direction space are exactly the sets
with , again by Proposition 22.2.1.
Parallel flats have the same dimension. Some authors
also call a line parallel to a plane containing its
direction; we do not, and we say “” when we mean that.
When two
flats meet, and how big their join is
Here is the central computation of the section. Two
subspaces of a vector space always meet, in at least. Two
flats need not, and the dimension formula splits
accordingly.
Theorem
22.2.4 (Intersection and Join of Two
Flats)
Let be
flats of , and
choose and
. Parts (a)
and (b) need no hypothesis on .
- (a) .
- (b) if
and only if ; and then is a flat whose direction space is .
- (c) Let be finite. If
, then If , then
- (d) Let be finite. If
, there is a hyperplane of with and
,
and the two flats ,
are parallel, distinct, and disjoint.
Idea. Everything is read off from
one subspace, . The three
summands are forced: the join must contain the
directions of and
of , and it must
contain a way of getting from to . Whether the third
summand is already inside the first two is exactly
whether and meet — and that one
extra dimension, present precisely when they miss each
other, is the whole difference between (c)’s two
cases.
Proof. Put , a subspace of , and , a flat by Proposition 22.2.1.
- (a) First, .
Indeed . And each point of is with ,
which equals by Lemma 22.1.1 (b), and
. So is one of the flats
being intersected in Definition 22.2.2, whence
.
Conversely, is a flat containing , so by Proposition 22.2.1 (b),
where is the
direction space of . Since and , part (a) of that
proposition gives . Since , also
. And for the point lies in
, so , and
therefore . Hence , that is, . The
two inclusions give (a).
- (b) Suppose
with ,
. Put , a point of . Then so . Hence .
If
,
then and by Proposition 22.2.1 (a),
so . The last clause is Proposition 22.2.2
applied to the two flats and .
- (c) Case 1:
. By (b), , so . By (a) and Theorem 1.7.3, and by (b), which is
the first formula.
Case 2: . By (b), ; in particular . Then since a nonzero
lying in would give , being nonzero and
hence invertible. So Theorem 1.7.3
applied to the two subspaces and
gives , and one more application, as in
Case 1, gives the second formula.
- (d) Put and
. By (b),
, so appending to a
basis of leaves an independent
list (Lemma 1.5.3). Extend
it to a basis of by
Theorem 1.6.5, and
let . Then , so by Theorem 4.4.5 and
is a hyperplane
(Definition 5.5.2). Now
gives , and likewise
.
The flats and
are parallel
by Definition 22.2.3. They
are distinct: if they were equal, then would give
, contradicting the independence of the
displayed basis. Being parallel and distinct, they are
disjoint by Proposition 22.2.3. This
proves the theorem.
The two formulas in (c) are best read side by side.
When the flats meet, the count is the subspace count of
Theorem 1.7.3, with
in the
role of . When they miss, the correction term is taken
among the directions, where the flats
always do meet, and a is paid for the
displacement that carries one flat to the other.
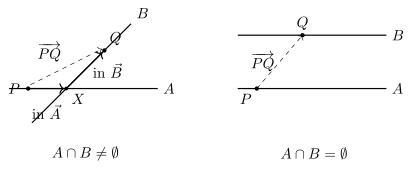
Part (b) is what the two pictures below show. On the
left the displacement
splits as a step inside followed by a
step inside , and the flats
meet; on the right it does not split, so it contributes
a direction of its own to the join.
Example
(Two lines in space, twice)
In let
Decide in each case whether the lines meet,
and compute and .
Solution. Here , and .
and
. The
directions
and are
independent, and is the plane of vectors with third
coordinate . Since
has third coordinate , it is not in , so by
Theorem 22.2.4 (b): the
lines are skew, that is, disjoint and
not parallel. (Directly: forces .) Also , the two directions being
independent. The second formula of (c) gives so : two skew lines span the whole space.
and
.
Now , so the lines are parallel, and
they are distinct because ; hence they are disjoint (Proposition 22.2.3). Here
has dimension , so and is the plane , by part (a).
Warning. There is no
convention for that makes
one formula do both cases. It is tempting to
set and keep writing . For the skew lines of Example (Two lines in space, twice)
that gives , which is right; for the parallel lines and it gives as well, and the
correct answer is . The two disjoint cases
differ in , which the empty intersection cannot
record. Use the second formula of Theorem 22.2.4 (c), and
always check first whether the flats meet.
Quick check. In , let and be planes (flats of
dimension ) with
. Must they meet?
Solution. Yes. By Theorem 1.7.3, , so by Theorem 1.6.8. Hence
for any , , and Theorem 22.2.4 (b) gives
. (The dimension formula agrees: the
disjoint case would predict ,
which is impossible.) Their intersection is then a
single point, since its direction space is .
Affine
frames and barycentric coordinates
To put coordinates on an -dimensional vector
space we choose
vectors. To put coordinates on an -dimensional affine
space we must also say where the origin is, so we choose
points — and
if we refuse to single out one of them, the coordinates
come out symmetric in all . That symmetry is what makes the centroid
computation below one line.
Chapter 18 §02 defined a list in a real vector space to be
affinely independent when the only
scalars with and are all zero (Definition 18.2.1). By
Definition 22.1.2 (b) the
expression is a
well-defined vector for points of an affine space
whenever , so the same words apply here verbatim. The
next lemma is Lemma 18.2.1 (a) in that
setting; its proof uses nothing about , so we give it again
over an arbitrary field.
Lemma
22.2.5 (Affine Independence by
Differences)
Let . The following are equivalent.
- (a) The only with
and are .
- (b) The list is linearly
independent in .
A list satisfying these is called affinely
independent. Condition (a) does not mention
specially, so
(b) holds with any in place of as soon as it holds
for one.
Proof. By Definition 22.1.2 (b)
computed with origin , and since , Given , the condition
holds for exactly one , namely ; and is the zero list exactly when is. So the relations forbidden by
(a) correspond, one for one, to the nontrivial linear
relations among , and (a) holds if and
only if there are none, which is (b).
Over with
this is Lemma 18.2.1 (a), and
Chapter 18’s warning applies unchanged: affine
independence is not linear
independence. The list in is linearly
dependent and affinely independent, which is why the
count below is and not .
Definition
22.2.4 (Affine Frame)
Let . An affine frame of is a list of
affinely
independent points of .
By Lemma 22.2.5 the list
is then
independent with entries, hence a basis of (Theorem 1.6.4);
conversely, if it is a basis, the frame condition holds.
So an affine frame is “a point together with a basis”,
written symmetrically. In the
standard frame is .
Theorem
22.2.6 (Barycentric Coordinates)
Let
and let be an affine frame of . For every there are
unique scalars
with They are called the barycentric
coordinates of with respect to the
frame.
Idea. Existence is the basis
expansion of ,
with invented
to make the weights add up to . Uniqueness is affine
independence: the difference of two weight lists is an
affine dependence.
Proof. Existence. The list
is a basis of
, so there are
unique with (Theorem 1.5.1). Put
, so that .
Computing the affine combination with origin ,
Uniqueness. Suppose with both weight lists summing to
, and put . Then , so
is the vector of Definition 22.1.2 (b),
and computing both combinations with origin gives By Lemma 22.2.5 (a), every
. This
proves the theorem.
Barycentric coordinates come as a
list, not as separate numbers: they are
pinned down only by the requirement that they add up to
, so no one of
them means anything on its own. Their virtue is that the
frame’s points are treated alike: has coordinates
with the in slot
, for every .
Example
(Reading a triangle)
In take
the frame , , .
- (a) Check that it is
a frame, and find the barycentric coordinates (Theorem 22.2.6) of .
- (b) Find the point
with barycentric coordinates .
- (c) Describe the
line
in barycentric coordinates.
Solution.
(a) and are independent, so by Lemma 22.2.5 the list is
affinely independent, and three points in a plane make a
frame. For : from we get and , so . The coordinates are . Check: , and .
(b) .
(c) The join of
the two distinct points is by Theorem 22.2.4 (a), a
line. Its points are the affine combinations , whose
barycentric coordinates are ; conversely a
point with
is such a combination. So . The point of (a) has
and so is not on it.
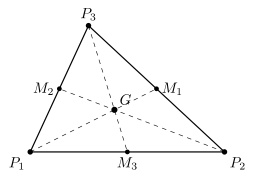
The next result is the advertisement for the whole
apparatus: a classical theorem of plane geometry, proved
in one line of arithmetic with weights.
Idea. Work in the plane , where is an affine frame, and give every
point its barycentric coordinates. A median is then the
set of coordinate triples of one shape, and the three
shapes have exactly one triple in common.
Proof. The three points are
affinely independent, so is independent by Lemma 22.2.5 and, by Theorem 22.2.4 (a)
applied twice, is a plane in which
is
an affine frame. All the points named lie in , being affine
combinations of , so we may use the barycentric coordinates
of Theorem 22.2.6
throughout; the weights and exist because
and are nonzero, hence
invertible, in .
Each is
a line, and lies
on it. Take . In coordinates and , so by the uniqueness in Theorem 22.2.6, and by Theorem 22.2.4 (a), a
flat of dimension
because . Its points are the affine
combinations , , with coordinates At this is , the coordinate triple of . So , and by the
same computation with the indices permuted, and .
No other common point. A point of has
coordinates and for some .
Uniqueness in Theorem 22.2.6 makes the
two triples equal entry by entry. The third entries give
, and
then the first two give , that is, and . So , and
a fortiori .
The ratio. With origin we have and , so and . Hence , and likewise for . This proves the
proposition.
An affine
map is fixed by a frame
Barycentric coordinates make the next theorem
immediate, and it is the affine counterpart of “a linear
map is determined by its values on a basis”.
Theorem
22.2.8 (An Affine Map Is Determined by a
Frame)
Let have
dimension with
affine frame , let be an affine space
over the same field with direction space , and let
be any points. Then there is exactly
one affine map with for . Moreover carries the barycentric
coordinates of Theorem 22.2.6 across:
Proof. Existence. The list
is a basis of
, so by Theorem 2.1.6 there is
a linear with for . Define
; it is affine with
by Theorem 22.1.5 (c). Then
, and .
Uniqueness. Let be affine with for all
. By Theorem 22.1.5 (b), so
and agree on a
basis and are equal (Theorem 2.1.5). Hence
for every .
The displayed identity is Definition 22.1.3 applied
to ,
using .
So points
in the right position determine an affine map of an
-dimensional
space, and prescribe it freely. Fewer points never do,
and not because our proof is weak.
Proposition
22.2.9 (Points inside a proper flat do not
determine an affine map)
Let and let be contained in a flat with — for
instance, any set of at most points. Then there are
two distinct affine maps that agree at
every point of .
Proof. Let and let be a basis of , where . Extend
it to a basis of (Theorem 1.6.5);
since , the
vector
exists. Let be the linear map fixing each and each with , and sending
to (Theorem 2.1.6), and
put , an affine map by Theorem 22.1.5 (c).
For we
have ,
on which is the
identity, so . Hence agrees with on , and so on . But , since
by Lemma 22.1.1 (c).
Finally, a nonempty set of at most points does lie in such
a flat. Put This is the smallest flat containing : it is a
flat by Proposition 22.2.1 and
contains every ;
and any flat containing all the contains , hence equals with each , so it contains by Theorem 1.3.1. Thus
, and
gives
. (An empty lies in the flat for any .)
Example (Two points are not enough in the plane)
is an instance of this proposition, with and ; it
exhibits its own pair of maps rather than the pair the
proof constructs. The moral is the count: , never . It is the same count
that will govern projective transformations later in
this chapter, where the answer turns out to be .
A flat is
a solution set
Chapter 3 produced flats as solution sets; Chapter 5
proved that every subspace of is a null space.
Putting the two together identifies the flats of completely.
Theorem
22.2.10 (Flats Are Exactly the Solution
Sets)
Let be nonempty and . The
following are equivalent.
- (a) is a flat of dimension
.
- (b) for some with linearly independent rows and some
.
In that case no system with fewer than equations has
solution set , and
for the
flat is an
intersection of exactly affine hyperplanes.
Idea. A flat is a coset by Proposition 22.2.1,
Chapter 5 turns
into a null space, and Chapter 3’s “particular plus
homogeneous” turns the coset into the solution set of
the inhomogeneous system with the same matrix and
right-hand side .
Proof.
(a) (b). By Proposition 22.2.1, with
and
. By Theorem 5.6.2 (a) there is
with whose rows are the ones corresponding to
a basis of under the isomorphism
of Theorem 5.1.1; an
injective linear map preserves independence (Theorem 2.2.5), so
those rows are linearly independent. Put .
Then
solves , so by Theorem 3.1.3 the
solution set is .
(b) (a). The set
is nonempty, so
it has an element , and Theorem 3.1.3 gives
, a coset, hence a flat by Proposition 22.2.1 with
.
The rows of are
independent, so by Theorem 3.5.5, and
Theorem 3.5.7 gives
.
Minimality. Suppose
and satisfy . Fix . For any
,
holds if and only if , so if and
only if ; that is, .
Comparing with and using Proposition 22.2.1 (a),
. By Theorem 5.6.2 (b), .
Hyperplanes. Let and write for the rows of a matrix
as in (b). Each
vanishes on , hence lies in (Definition 5.2.1), and the
are
independent because the rows are and is an isomorphism (Theorem 5.1.1); as by Theorem 5.2.2, they are a
basis of (Theorem 1.6.4). So
is a matrix as
in Theorem 5.6.2 (a), and Proposition 5.6.4 applied
to and writes as the
intersection of the affine hyperplanes .
For the
system is empty and ; for it has
independent equations and is a single point. In
between, the count is the familiar one:
dimension counts parameters, codimension counts
independent equations, and now it holds for
flats as it did for subspaces.
Example
(Equations for a plane in four-space)
In Example (Equations for a plane in )
the subspace of was found to be
. Find equations for
the flat with , and give two of its points.
Solution. Take , whose null space is , and . By Theorem 22.2.10, a flat of dimension . Two points:
, with and ; and , with and . By the
minimality clause, no single equation cuts out , since .
That closes the affine part of the chapter’s
foundations. Flats are cosets, they meet or they do not,
their joins obey a two-case formula, they carry
symmetric coordinates, and in they are the
solution sets of linear systems. The one irritant is the
second case of the join formula, and the reason two
coplanar lines can fail to meet: in the affine plane,
parallel lines have nowhere to intersect. The projective
sections later in this chapter remove that exception by
adding the missing points.
Exercises
A. Check your
understanding
Exercise
(A1)
- (a) Define a flat
and its direction space, and say why the direction space
does not depend on the point used to compute it.
- (b) State both cases
of the dimension formula for , and say
which one applies to two distinct parallel planes in
.
- (c) True or false,
with a reason: the intersection of two flats is a
flat.
- (d) What are the
barycentric coordinates of with respect to the
frame of a three-dimensional affine space?
Solution.
(a) A flat is a
nonempty subset closed under affine combinations (Definition 22.2.1);
equivalently a coset with a
subspace of (Proposition 22.2.1). Its
direction space is , a
description that mentions only , so no choice of point
enters.
(b) If ,
; if ,
. Two
distinct parallel planes in are disjoint (Proposition 22.2.3), so
the second applies: , and their join is .
(c) False as
stated, because the intersection may be empty, and the
empty set is not a flat (Definition 22.2.1). It is
true that a nonempty intersection of
flats is a flat (Proposition 22.2.2). Two
parallel lines in give the
counterexample.
(d) : the
combination has
weights summing to and equals , and the coordinates
are unique by Theorem 22.2.6.
B. Practice
Exercise
(B1: Two flats in four-space)
In let
, and let
For each of and , decide whether it
meets , and
compute . Justify your answers with Theorem 22.2.4.
Solution. Here , , . The three spanning
vectors are independent (the first two have disjoint
supports, and would need and ), so
and .
. Here and . If , the second coordinate
gives and the
first gives , so ; the third then gives , so , and the fourth
gives , a
contradiction. So and by part (b) of the theorem. Part
(c) gives , so .
. Here
and , so . Following the proof
of part (b), the meeting point is , and indeed .
By part (b) the direction space of is , so the intersection is the single
point ,
of dimension , and
.
Exercise
(B2: Barycentric arithmetic)
In take
the frame , , .
- (a) Verify that it
is a frame.
- (b) Find the
barycentric coordinates (Theorem 22.2.6) of .
- (c) Find the
centroid of in ordinary coordinates, and check its
barycentric coordinates.
Solution.
(a) and are independent, so the list is affinely
independent by Lemma 22.2.5, and it has
entries.
(b) gives , , so . The coordinates are . Check: .
(c) . Its
barycentric coordinates are
by definition, and by uniqueness these are the only
ones. Check against (b)’s method: , so and
.
Exercise
(B3: From parameters to equations and back)
- (a) Find a system of
equations whose solution set is the line in , using as few
equations as possible.
- (b) The set is a flat. Find its dimension,
a point of it, and its direction space.
- (c) Decide whether
, and
compute .
Solution.
(a) Here and , so Theorem 22.2.10 calls for
equations, and no fewer will do. A functional
vanishes on exactly
when ; two independent such rows are and . With the
right-hand sides are and , so Check: satisfies both,
and so does .
(b) One equation
with a nonzero row, so by Theorem 22.2.10, a plane.
The point
lies in it, and .
(c) has
, so
; but
, since . So , while
(it contains ). Since , the intersection is the single
point
and : the line and the plane together span
.
C. Going deeper
Exercise
(C1: Affine maps and flats)
Let be affine and let be a
flat.
- (a) Prove that is a flat of whose direction space
is , and
deduce .
- (b) Prove that if
is
a flat with , then is a flat with
direction space .
- (c) Hence prove that
an injective affine map sends flats to
flats of the same dimension, and lines to lines.
Solution.
(a) is nonempty. Let
, so (Proposition 22.2.1). For
, Theorem 22.1.5 (c) gives
. Hence , and is a
subspace of ,
being the image of the linear map restricted to the
subspace
(Theorem 2.2.2 applied
to that restriction). So is a flat by Proposition 22.2.1, with
the stated direction space, and , because the images of a
basis of
span
(Theorem 2.2.4) and a
spanning list is at least as long as the dimension (Theorem 1.6.3
(b)).
(b) Let , so . For , lies in exactly
when . So , and is a subspace: it contains
and is
closed under linear combinations by linearity of and the subspace
test (Theorem 1.2.1). By
Proposition 22.2.1, is a flat with
that direction space.
(c) If is injective, then
is
injective: gives ,
hence and . An injective linear map carries a
basis of to
a linearly independent list (Theorem 2.2.5) that
spans , hence to a basis of it; so by (a). A line has
dimension , so its
image is a flat of dimension , a line.
Exercise
(C2: The midpoint quadrilateral)
Let be a field
with , let
be an affine
space over , and
let be any four points. Put , and define
likewise.
- (a) Prove that .
- (b) Deduce that if
are distinct, then and
are parallel lines, and likewise for the other pair of
opposite sides: the four midpoints form a
parallelogram.
- (c) What does the
statement say when are not coplanar, for
instance in ?
Solution.
(a) Fix any
origin and write
. By Definition 22.1.2, and similarly
for the others. Hence, by Proposition 22.1.3, and The answer does not depend on , as it must
not.
(b) If , the
join is the line by Theorem 22.2.4 (a). By
(a) the two lines and have
the same direction space ,
so they are parallel (Definition 22.2.3).
Running (a) with the indices shifted by one gives , so the other
two sides are parallel too.
(c) Nothing in
(a) used coplanarity, so the conclusion holds for a skew
quadrilateral in as well: the four
midpoints of a skew quadrilateral are coplanar and form
a parallelogram. Four noncoplanar points are affinely
independent: otherwise would be dependent (Lemma 22.2.5) and span a
subspace of dimension at most , putting all four
points in a flat of dimension at most . The four midpoints are
then distinct, since the difference of two of them is
with and the not all zero —
for and
the weights
are at
and at — hence is a nonzero
vector; so (b) applies. The two parallel lines and
are also distinct: were they equal, their common
direction space would contain ,
which is
by (b), so for
some (Proposition 22.2.1 (a)) —
a relation with weights summing to and at , again against affine
independence. Their join is therefore a plane, of
dimension by Theorem 22.2.4 (c), and
it contains all four midpoints.
Exercise
(C3: Medians over the field with three elements)
Work in with the
affinely independent list , , . (Nothing is
lost by this choice: by Theorem 22.2.8 any other
affinely independent triple is carried to this one by an
affine bijection, which preserves midpoints, being an
affine combination, and carries lines to lines by Exercise (C1: Affine maps and flats).)
- (a) Compute the
three midpoints
and the three medians .
- (b) Prove that the
three medians are pairwise parallel and pairwise
disjoint, so that Proposition 22.2.7 fails
over .
- (c) Explain which
step of the proof of Proposition 22.2.7
breaks, and why the hypothesis cannot be
dropped.
Solution.
(a) In we have , since . So
Then , and . So
(b) All three
have the same direction space , so they are parallel (Definition 22.2.3). They
are distinct: , and likewise for the other
two pairs, so no two of them share a point by Proposition 22.2.1 (b).
Distinct parallel flats are disjoint (Proposition 22.2.3).
Hence the three medians have no common point, and the
conclusion of Proposition 22.2.7 is
false here.
(c) The proof
solved for ,
which needs to be
invertible. Over the point
does not exist, because has no inverse; the weights
cannot be written down at all. Concretely, the equation
becomes , that is,
, which
has no solution: the parametrizations of and never agree. So the
hypothesis
is not an artifact of the proof; it is needed for the
statement.