Spanning lists and independent lists each solve half
of a problem. A spanning list reaches every vector of
the space, but it may reach some vectors in more than
one way. An independent list never wastes a vector, but
it may not reach everything. This section puts the two
halves together. The result, a basis, turns an abstract
vector space into columns of numbers, and we prove that
every space spanned by a finite list has one.
What makes
coordinates work
Start with the plane. Every vector of can be written as
and the pair is its address. Two separate facts make this
addressing system work. First, every
vector has an address: the list
spans .
Second, every vector has only one
address: if , then , so and .
Nothing about this is special to and . Take instead
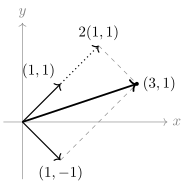
the list . To find an address for we solve Adding and subtracting the two equations gives
and
. So
there is a solution, and it is the only one: For example , and no other pair of
scalars works. The grid is slanted, but every point
still has exactly one address.
Look at which property did which job.
Existence of an address is spanning.
Uniqueness of the address is
independence: by Theorem 1.4.3, a
list is independent exactly when every vector in its
span has only one expression as a combination of it. A
coordinate system is a list that does both jobs at
once.
A basis is a list with enough vectors to build
everything and no vector to spare.
Bases
Definition
1.5.1 (Basis)
Let be a
vector space over . A
basis of is a
list of vectors in such that
- (B1) is linearly
independent, and
- (B2) spans , that is, .
We usually name a basis with a calligraphic letter,
, and call its
length. The plural of basis is
bases.
In words: (B1) says that the only combination of the
equal to
is the one
with all coefficients zero, so no
vector in the list is wasted. (B2) says that
every vector of is some combination of
the , so
nothing is out of reach. The basis is a list, so its
entries come in a definite order, and a basis is always
a basis of a particular space:
is a basis of , but not of .
We start with the bases that come with the running
examples.
Example
(Standard Bases)
Show that each of the following lists is a basis.
They are called the standard bases.
- (a) in , where has in position and elsewhere.
- (b)
in .
- (c) in , where
the matrix unit has in entry and elsewhere, listed row
by row.
Solution.
(a) (B2): every
equals . (B1): let . The left side is the
column , so comparing entries gives .
(b) (B2): by Definition 0.8.4,
every element of has the form , which is a combination
of . (B1): let . Here is the zero polynomial,
all of whose coefficients are . Two polynomials are
equal exactly when their coefficients agree (Definition 0.8.1), so
.
(c) (B2): a
matrix equals , since both sides have in entry . (B1): if
is the zero matrix, then its entry is for every .
The next examples show that a space has other bases,
that the field matters, and what happens in the smallest
space.
Example
(Three More Bases)
Show that each list is a basis.
- (a) in
.
- (b) in , regarded as a vector
space over .
- (c) The empty list
in the zero
space .
Solution.
(a) We showed
above that for every the equation has a solution, so (B2) holds. Taking , the only
solution is and , so (B1) holds.
(b) The scalars
are now real. (B2): every complex number is with (Definition 0.6.1).
(B1): let with . A complex number is exactly when its real
and imaginary parts are , so .
(c) The empty
list is linearly independent: there are no coefficients,
so the condition “all coefficients are zero” holds
vacuously. Its span is by the
convention for the empty span. So both (B1) and (B2)
hold.
The degenerate case (c) matters more than it looks.
Without it, the zero space would be the one space with
no basis, and every theorem below would need an
exception for it.
Nonexamples by minimal change. Add
one vector to the standard basis of , making .
Spanning (B2) still holds, since the first two vectors
already span. But (B1) fails: with coefficients not all
zero. The effect is exactly the loss of unique
addresses: .
Now remove a vector instead. In , the list is
still independent, since forces . But (B2)
fails: every combination has third entry , so is out of
reach.
Quick check. Is
a basis of ?
If not, which of (B1) and (B2) fails?
Solution. No. (B2) holds: and already span , because solving
gives and . But
(B1) fails, because the list contains the zero vector:
with a nonzero coefficient.
Why this definition. Drop (B1), and
addresses stop being unique, as the list
showed. Drop (B2), and some vectors have no address at
all. Keeping both is exactly what an addressing system
needs. The name comes from the everyday word: the basis
is what everything else is built on.
Warning. Say a
basis, not the basis. A space usually
has many bases; a nonzero space over an infinite field
such as has
infinitely many. For instance is a
basis of for
every real number , since , and this is the only solution. The standard
basis is a convenient choice, not a canonical one.
Unique
representation and coordinates
We found the definition by asking for addresses that
exist and are unique. The first result confirms that
this is exactly what a basis delivers, and nothing
more.
Theorem
1.5.1 (Unique Representation)
Let be a
vector space over , and let be a list in . Then is a basis of if and only if every
can
be written as in exactly one way.
Proof. Let . Since
spans , there are scalars with
. Suppose also . Subtracting the two expressions
and regrouping with the vector space axioms, Since
is linearly independent, for every . Hence the two
expressions are the same.
Every is a combination of , so spans . For independence, let
. We also have . By uniqueness of the expression
for the vector , all . Hence is linearly
independent, and is a basis.
This is Theorem 1.4.3 in the
special case where the span is the whole space. The
theorem also gives a second way to check that a list is
a basis: solve for the coefficients of a general vector,
and see that there is always exactly one solution. We
did exactly that for .
Whenever something exists and is unique, it deserves
a name.
Definition
1.5.2 (Coordinates)
Let be a basis of a vector space
over , and let . The
unique scalars with are the
coordinates of with
respect to . The column is the coordinate vector of
with
respect to .
In the standard basis of , the coordinate
vector of is the column itself.
That is why we rarely notice coordinates in . In other bases and
other spaces they carry real information.
Example
(Coordinates of a Polynomial)
Show that is a basis of , and find
for
.
Solution. We use Theorem 1.5.1. Let
be arbitrary. For scalars , Two polynomials are equal exactly when their
coefficients agree, so this equals if and only if Solving from the top, , then , then . So every
has exactly one
expression, and
is a basis of .
For we have , , . Hence , , and : Check: . In the standard basis , the same
polynomial has coordinate vector .
Warning. Coordinates depend on the
basis and on its order. Take . With respect to the standard basis , . With respect to ,
. With respect to , the same two vectors in the other order,
. A column of numbers means nothing until
you say which ordered basis it refers to.
The point of coordinates is that they turn
computations in
into computations with columns. That works because they
respect the two operations.
Theorem
1.5.2 (Coordinates Respect the
Operations)
Let be a basis of a vector space
over . Then for all
and , Moreover, every column
is the coordinate vector of exactly one vector of , namely .
Proof. Let and . By the vector space axioms, By Theorem 1.5.1 these
are the only expressions of and
in , so their
coefficients are the coordinates: and , as claimed.
For the last statement, let
and . By Definition 1.5.2,
. If also , then by definition .
So a basis of length sets up a bijection
between and that respects
addition and scaling. Any question about sums and
multiples in can
be answered in
instead. In Chapter 2 we will call such a correspondence
an isomorphism.
Every
finite spanning list contains a basis
Where do bases come from? A finite-dimensional space
is, by Definition 1.3.4, a
space spanned by some finite list. That list reaches
everything but may contain waste, so the natural plan is
to throw the waste away.
Care is needed about what to throw
away. In each vector is a combination of the
other two. Any single one can go, but not two of them.
So redundancy is not a property of one vector alone: it
depends on which other vectors stay. The fix is to
decide one vector at a time, reading from left to right,
and to compare each vector only with the vectors already
kept.
First, a small lemma that tells us when a kept list
stays independent.
Lemma
1.5.3 (Appending a Vector to an Independent
List)
Let be a linearly independent list in a
vector space , and
let .
Then is linearly independent
if and only if .
Proof. Suppose
, say . Then , with
the coefficient . So the longer list is dependent. This proves
by
contraposition.
Suppose , and let
. If , then exists and a contradiction. Hence . Then , and the independence
of gives . So
all coefficients are zero, and the longer list is
independent.
The direction is Exercise (C2: Adding a Vector outside the Span).
When , the
lemma says that the one-vector list is independent
exactly when , that is, when , in
agreement with Example (Degenerate Lists).
Now the procedure. Given a list in ,
sifting it means the following.
Algorithm. Start with the empty
list . For
in turn:
- if , keep it: ;
- if , discard it:
.
The final list is the sifted
list of .
Here means the list with appended at
the end. Each
is a sub-list of : it is obtained by deleting some
entries and keeping the rest in their original
order.
Theorem
1.5.4 (Sifting Theorem)
Let be a list in a vector space , and let be its sifted list.
Then is
linearly independent and In particular, every finite list that spans
contains a
sub-list that is a basis of .
Idea. Sifting protects two things
at every step. A vector is kept only when it lies
outside the span of what was kept before, so by Lemma 1.5.3 the kept
list stays independent. A vector is discarded only when
it is already in that span, so by Theorem 1.3.5
discarding it loses nothing. We turn “at every step”
into an induction on , the number of vectors
read so far, with the invariant: is independent and
has the same span as .
Proof. We prove by induction on
the statement
: the list
is linearly
independent and .
Base case. is the empty list,
which is linearly independent, and both sides of the
span equation are the span of the empty list. So holds.
Inductive step. Let and suppose
holds. Put
,
so that by
.
Case 1: . Then , which is
independent. Since , Theorem 1.3.5 gives
.
Case 2: . Then . Since is independent
and , Lemma 1.5.3 shows
that is
independent. For the spans, recall from Theorem 1.3.1 that
the span of a list is a subspace, and is contained in
every subspace containing the entries of the list. Every
entry of is one
of , so .
Conversely, is a subspace
containing the entries of , so it contains
, and with it
; it also contains . Hence .
In both cases holds. By induction
holds, which
is the first statement.
Finally, suppose spans . Then is a sub-list of it
that is independent and satisfies . So is a basis of .
Alternatively, one can delete instead of keep. As
long as the list is dependent, the Linear Dependence
Lemma (Theorem 1.4.1)
locates an entry lying in the span of the entries before
it, and deleting that entry does not change the span.
Each deletion shortens the list, so the process stops
after at most
steps. Sifting performs the same idea in a single
left-to-right pass.
The decision “is in the span of
the kept vectors?” is a small system of equations. For
now we solve these systems by hand; Chapter 3 gives a
systematic method.
Example
(Sifting a List in )
Sift the list in , where Hence find a basis of inside the
list.
Solution. We go through the list
once, comparing each vector with the vectors kept so
far.
- : the
kept list is empty, with span . Since ,
keep .
- :
.
Discard.
- : if
, the first entry gives and the second
gives , a
contradiction. So .
Keep.
- :
,
so .
Discard.
- :
suppose . The second
entry gives
and the third gives , a contradiction. So .
Keep.
- :
,
so .
Discard.
The sifted list is . By Theorem 1.5.4 it is
independent and has the same span as the original list.
That span is all of , since it contains
, , and ,
and hence every combination of them. So is a basis of .
Sifting has no memory of the future, so its output
depends on the order of the input.
Example
(The Order Matters)
Sift and in .
Solution. For the first list: , so
keep it. Every multiple of has second entry
, so ; keep it. Then ;
discard it. The result is .
For the second list: , so keep it. If , then and , which is impossible; keep . Then ;
discard it. The result is .
Both results are bases of (the lists span
because they
contain
and ),
but they are different bases. A zero vector, by
contrast, is discarded wherever it stands, because lies in every
span.
Quick check. Sift the list in
.
Which vectors are kept?
Solution. Keep , since . Discard . Keep
: every
multiple has
constant term ,
but has
constant term .
Discard . The sifted list is .
The theorem answers the question we started with.
Corollary
1.5.5 (Existence of Bases)
Every finite-dimensional vector space has a
basis.
Proof. Let be finite-dimensional.
By Definition 1.3.4,
is spanned by
some finite list. By Theorem 1.5.4, that
list contains a sub-list that is a basis of .
For the proof still works: is spanned
by the empty list, and sifting it returns the empty
list, which is the basis found in Example (Three More Bases).
We now know that bases exist, and we can find one
inside any finite spanning list. But a space has many
bases. The next section proves the fact that makes them
measurable: all bases of the same space have the same
length.
Exercises
A. Check your
understanding
Exercise
(A1)
- (a) Define what it
means for a list to be a basis of a vector space
over .
- (b) True or false:
every list that spans is a basis of . Justify your
answer.
- (c) True or false:
and are the same basis of . Justify your
answer.
- (d) What is a basis
of the zero space ?
- (e) When sifting a
list, under what condition is the vector
discarded?
- (f) True or false:
if is a basis
of and , then .
Justify your answer.
Solution.
(a) See Definition 1.5.1:
the list is linearly independent and spans .
(b) False.
spans , but it
is dependent, since .
(c) False. A
basis is a list, and the two lists have their entries in
different orders. The difference is visible in
coordinates:
has coordinate vector in the first basis and in the
second.
(d) The empty
list , by Example (Three More Bases)
(c).
(e) When lies in the
span of the vectors kept before it, that is, .
(f) True. If both
coordinate vectors equal , then
by Definition 1.5.2,
where .
B. Practice
Exercise
(B1: A Basis of and
Coordinates)
Let . Show that is a basis of . Hence find for
.
Solution. Let . For
scalars ,
so this equals if and only if , , and . Adding the
three equations gives , so . Subtracting each equation from this one,
Conversely, these values satisfy the three
equations: for instance , and the other two are
checked the same way. So every vector of has exactly one
expression in ,
and is a basis
by Theorem 1.5.1.
For : , , . Check: . Hence
.
Exercise
(B2: Sifting Polynomials)
Sift the list in
,
justifying each decision. Hence find a basis of contained
in the list.
Solution. We read the list from
left to right, comparing coefficients.
- :
keep.
- : discard.
- : every
multiple
has -coefficient
, while has -coefficient . So :
keep.
- : discard.
- : suppose
. The constant terms give and the -coefficients give , a contradiction.
So : keep.
- : discard.
The sifted list is . The original list contains , , and , so its span contains
every combination of them, which is all of by Example (Standard Bases).
Hence the list spans , and by Theorem 1.5.4 the
sifted list is a basis of .
Exercise
(B3: Symmetric Matrices)
Let . Show that is a basis of , and find the
coordinate vector of with respect to it.
Solution. Each of the three
matrices is symmetric, so the list lies in .
Spanning. Let . Writing , the condition says . Hence
Independence. Let . The left side is , so comparing entries
with the zero matrix gives .
Hence the list is a basis of . Reading off , , , the coordinate
vector is .
C. Going deeper
Exercise
(C1: Polynomials Vanishing at 1)
Let be a
field, , and
.
- (a) Prove that is a basis of .
- (b) For , find the
coordinate vector of with respect to this basis.
Hint: for , what does say about ?
Solution.
- (a) For , evaluation gives , since every power of is . In particular each
lies in
, because .
Spanning. Let . Then , so
Independence. Let . For , the coefficient of on the left is , since appears in no other
term. The zero polynomial has all coefficients , so for every .
Hence the list is a basis of .
- (b) For we have
, and . By the formula in (a), . Check: . The coordinate
vector is .
Exercise
(C2: The Same List over a Different Field)
- (a) Explain why
is not a basis of .
- (b) Let be any field. Prove
that is a basis of if and only if in .
Solution.
(a) In we have , so the list is
.
It is dependent:
with nonzero coefficients. (It also fails to span: every
combination is , so is out of reach.)
(b) Write .
Suppose , so
exists. Let
. The
equation says and . If it holds, adding and subtracting gives
and
, so
and . Conversely these values satisfy and . So every vector has
exactly one expression, and the list is a basis by Theorem 1.5.1.
Suppose . Then
, and the
argument of (a) applies word for word: , so the list is dependent and
is not a basis. This proves by
contraposition.
Exercise
(C3: Rescaling a Basis)
Let be a basis of over , and let be
nonzero.
- (a) Prove that is a basis of .
- (b) Express
in terms of .
- (c) Explain why the
conclusion of (a) can fail if some .
Solution.
(a) Let and . Since each , exists, and
So has an
expression in . Suppose .
By uniqueness of the expression in (Theorem 1.5.1),
for
each , so . Hence
the expression in is unique, and
is a basis
by Theorem 1.5.1.
(b) By (a), : divide the
-th coordinate by
.
(c) If , then contains ,
and is a combination with a nonzero
coefficient. So is dependent and
is not a basis.