Section 06 built out of the lines
through the origin of , and a construction is
only as good as the maps that go with it. Here the maps
are already in hand: an invertible linear operator sends
lines through the origin to lines through the origin, so
it permutes the points of . This section
shows that two operators give the same permutation
exactly when they differ by a nonzero scalar, that such
a map is pinned down by its values on points in general
position — and, over any field with more than two
elements, not on — and that the
failure at is
precisely what makes the cross-ratio of four points on a
line a genuine invariant.
Throughout, is
an arbitrary field and , are finite-dimensional
vector spaces over . Nothing in this
section needs a characteristic assumption, an ordering
or an inner product. In we index
coordinates from ,
writing and for the standard basis, so that
homogeneous coordinates read
as in Definition 22.6.2. We
write for the multiplicative group of
(Example (Groups)), and
for the set
of invertible linear operators ; composition
makes a
group (Definition 0.10.1),
with identity , exactly as it
makes
one.
Maps
induced by linear isomorphisms
We need maps , and the only structure a projective
space has is its supply of points, that is, of
one-dimensional subspaces (Definition 22.6.1). So we
want maps that carry one-dimensional subspaces to
one-dimensional subspaces. A linear map does this as soon as it
kills nothing: , and the right-hand side is a
line precisely when .
A projective transformation is an invertible
linear map, read on lines instead of on
vectors.
Two things must be checked before the formula means
anything, and both use invertibility. First, has to be a
point at all: a point of is for a
nonzero , and if
then , because is injective (Theorem 2.2.3).
Second, the recipe must not depend on the
representative: if ,
then for some
(Definition 22.6.2), so
and .
Proposition
22.7.1 (Projectivities Compose and
Invert)
Let and be isomorphisms of finite-dimensional
vector spaces over . Then , the
map is a
bijection with inverse , and .
Proof. For with ,
, and is an isomorphism as a
composition of isomorphisms (Theorem 2.5.3). Taking
gives
, and , so ;
taking the composition in the other order gives . Hence is a bijection with
inverse .
Examples. Take , so that
a projectivity of is for an invertible .
-
gives the identity, and so does for
any ,
since . This degenerate case is the whole
content of the next subsection.
- On ,
the matrix sends to . In the chart
, where
is the
scalar , this is
for
, and it
exchanges
with . A
projectivity repairs the one defect of : on the
projective line there is no missing value.
- On , a
permutation matrix permutes the three coordinate points
, , .
Nonexample by minimal change. Drop
invertibility. On put . For the recipe gives
, which is
fine; but , and is not a point
of . The
formula fails on exactly the points of , and
injectivity is the clause that rules them out. The
recipe does still make sense on the remaining points
, but it is
no longer injective there: for
every , so all of
them go to the single point .
Projectivities respect everything is made of.
Proposition
22.7.2 (Projectivities Preserve Subspaces,
Joins, and Meets)
Let be an isomorphism and let be a subspace of . Then a projective subspace of of the same
dimension as , and the
restriction of
to is the
projectivity induced by the isomorphism .
Consequently
preserves inclusion, intersections, and joins of
projective subspaces.
Proof. By Definition 22.6.3, and .
A point of is with , and these are exactly the points with , since is a bijection from
onto . Hence .
The restriction is linear and
injective with image , hence an
isomorphism onto , so (Theorem 2.5.4) and the
two projective subspaces have equal dimension; and agrees with on by the same
formula.
For the last sentence, preserves inclusion of
subspaces and satisfies and , the first because is injective and the
second because is
linear and surjective onto its image. Passing to
projective subspaces, inclusion transfers in both
directions by Lemma 22.6.4,
intersections by Proposition 22.6.5 (a),
and joins by Proposition 22.6.5 (b),
in each case applied on both sides of .
The
projective linear group
Different matrices can induce the same projectivity:
and both act as the
identity on . The next
theorem says that this is the only way it happens, and
it is the reason the group of projectivities is smaller
than .
Theorem
22.7.3 (Projectivities and Scalars)
Let and let be isomorphisms.
- (a) if and only if
for
some .
- (b) The set of projectivities of
is a group
under composition, the projective linear
group of .
- (c) The map , , is a
surjective group homomorphism, and .
For
we write
for ;
part (a) then says that induce the same
projectivity of exactly when
for
some .
Idea. One direction is the
computation . For the other, put
, so
that the hypothesis says
for every : every nonzero vector is an
eigenvector of . That is far
stronger than it looks. Test it on , and : if
and are independent,
comparing coefficients forces their eigenvalues to
agree, and if they are dependent, the eigenvalue is
forced directly. So is a scalar. Parts (b)
and (c) are then bookkeeping with Proposition 22.7.1.
Proof.
- (a) If with , then for
every we have , so
by Definition 22.6.2. Hence
.
Suppose .
Put . For every ,
gives for some , hence
. So for each
there is a scalar with .
We show does
not depend on . Let .
Case 1: is dependent. Take a dependence
with not both zero. If then and ,
which is false; so and with , and because . Then and gives .
Case 2: is independent. Then , and Independence lets us compare coefficients,
giving .
So there is one scalar
with for all ,
and also for . Hence and .
(b) By Proposition 22.7.1, is
closed under composition and under inverses and contains
; composition of maps is associative. So
(G1)–(G3) of Definition 0.10.1
hold.
(c) Surjectivity
is the definition of ,
and by Proposition 22.7.1, so
is a
homomorphism (Definition 0.10.3).
Its kernel is , which by (a) is . This proves the theorem.
Warning. A projectivity has
no determinant, no trace, and no eigenvalues.
Only a matrix has those, and a projectivity of is a matrix only
up to a scalar. On , the matrices
and induce the same
projectivity but have determinants and , and traces and . In general , so the most one can hope
to define is modulo -th powers. What
is well defined is a fixed point:
says is an
eigenvector of ,
and being an eigenvector does not depend on scaling
.
Frames,
and how many points pin a projectivity down
A linear map is determined by its values on a basis.
A projectivity of is induced by an
matrix, which has columns, so the first guess is that points should
determine it. Over any field with more than two elements
the guess is wrong — the two-element field is a genuine
exception, and we return to it below — and the reason is
visible in Theorem 22.7.3: knowing
fixes each column of only up to its own
scalar, which leaves unknown scalars, while changing to costs only one.
One extra point supplies the missing information.
First, the hypothesis under which the extra point
helps.
Definition
22.7.2 (General Position)
Let . A list of points of is in
general position if for every
subset with , and any choice of representatives with , the
list is linearly independent.
The clause “any choice of representatives” costs
nothing: replacing by with does not change
whether a list is independent, so the condition may be
tested on one choice. For , which is the case we need, general
position says exactly that every of the points have
independent representatives; no subset of size
can be
independent in an -dimensional space,
which is why the bound
is there.
Examples. In , the four points
, , , are in general
position: the first three representatives form a basis,
and any three of the four are independent, since each of
the other three triples has determinant . In , general
position for three points means simply that they are
pairwise distinct. The same holds in every dimension:
the points
, of are in general
position. Indeed of the
representatives are either the
themselves, with determinant , or all of them but
one, say , together with
; in
that matrix row
is zero except for the entry in the last column, and
expanding along row leaves the determinant
of a permutation matrix, so the value is . In , a single point
is always in general position, since one nonzero vector
is independent.
Nonexample by minimal change.
Replace by
. The list
, , , fails: the subset
has
representatives , , , and the third is
the sum of the first two. Geometrically, three of the
four points are collinear. No projectivity carries the
first list to this one: a projectivity preserves joins
and their dimensions (Proposition 22.7.2), and
here is a line, while is the whole plane.
The key step is that general position lets us choose
representatives once and for all.
Lemma
22.7.4 (Normalizing a Frame)
Let and let be points of in general
position. Then there are representatives with such
that Moreover such a list is unique up to one
common scalar: if is another, then for all , with a single .
Idea. Start from arbitrary
representatives . The first
form a basis,
so
has coordinates in it. General position is exactly the
statement that no coordinate is zero: a
vanishing would
put
in the span of the other basis vectors, making
of our points
dependent. Nonzero coordinates can be absorbed into the
basis vectors, and then the last vector is the sum of
the others. For uniqueness, write the second list as
and
read off from the relation that all coincide.
Proof. Choose any representatives
with
.
By Definition 22.7.2 the
list is independent, and it has
entries, so it is a basis of (Theorem 1.6.4).
Write Every is nonzero.
Suppose for
some .
Then is a linear relation whose coefficient on
is
, so the
list consisting of together
with the vectors
(, ) is dependent
(Definition 1.4.1).
It has
entries and its index set has elements,
contradicting Definition 22.7.2.
Now set for and . Each , so , and is still a basis, being the old
basis with each vector scaled by a nonzero scalar. By
construction .
Uniqueness. Let be another such list.
Since , there are with
. Applying the defining relation
to both lists, The list is independent, so comparing
coefficients gives for every . Hence all equal one scalar
.
The theorem is now three lines of linear algebra.
Theorem
22.7.5 (Fundamental Theorem of Projective
Geometry)
Let . Let be points of in general
position and points of in general
position. Then there is exactly one
projectivity with
Idea. Normalize both lists by Lemma 22.7.4. The first
normalized
vectors on each side are bases, so there is a unique
linear map sending one basis to the other, and the
normalization was arranged so that this map
automatically takes the -nd vector to the
-nd. For
uniqueness, a second projectivity differs from the first
by an operator that scales each of and also their sum; the same
coefficient comparison as in the lemma forces all the
scalars to agree.
Proof. By Lemma 22.7.4 choose
representatives of the with a basis of and , and likewise for the .
Existence. By Theorem 2.1.5 there is
a unique linear with
for . Its
image is by Theorem 2.2.4, so
is surjective,
and since is finite, is an isomorphism by Corollary 2.3.2 (e).
By linearity, Hence for all
.
Uniqueness. Let be a projectivity
with
for all , where
is
an isomorphism. Then , so there are with
. Put ;
then for every . Applying to , By independence of , for all . So
agrees with on a basis,
hence (Theorem 2.1.5), and
. By
Theorem 22.7.3 (a), . This proves
the theorem.
Existence and uniqueness are both used constantly:
existence says we may always choose
coordinates so that prescribed points in
general position become and ; uniqueness says that having done
so, nothing is left to choose.
Example
(Moving the standard frame)
Work in . Find the
projectivity carrying to after checking that the second list is in
general position.
Solution. General
position. Form the determinant of each triple of
representatives, taken as columns. For the triples , , , these
determinants are ,
, , . All are nonzero in
, so every
triple is independent (Theorem 7.5.2
together with the fact that the columns of an invertible
matrix are independent), and the four points are in
general position.
Normalizing. Following Lemma 22.7.4, we need
scalars with that is, , , . Adding all three gives , so , ,
. All are nonzero, as the lemma promised.
The matrix. The standard frame is already
normalized, with . So the map
sends to
, that
is, Check. The columns are , , , which represent
, , ; and ,
which represents . By Theorem 22.7.5 this is the only
projectivity doing this, so every other matrix that
works is a scalar multiple of .
Now the negative result promised above. It is not
that the proof of Theorem 22.7.5 is
wasteful; as long as has more than two
elements,
points genuinely do not suffice.
Proposition
22.7.6 (What Fixes the Coordinate
Points)
Let . A
projectivity of fixes each of
the points
if and only if it is for an invertible
diagonal matrix . The group of such
projectivities is trivial if and only if .
Proof. If with all , then , so .
Let fix each
. Then
for some . But
is the
-th column of
(Theorem 0.9.2), so
every column of
has a single nonzero entry, on the diagonal: .
For the last sentence, by Theorem 22.7.3 (a) we
have if and only if ,
that is, if and only if . So the group is trivial exactly
when every tuple is constant,
which, since , happens exactly when has one
element, that is, when .
Proposition
22.7.7 (Over the Two-Element Field, Points
Suffice)
Let and
. Given
two lists and of
points of , each in
general position, there is exactly one projectivity of
carrying to
for every .
Proof. Over the only nonzero
scalar is , so
each point has exactly one representative: write and
.
By Definition 22.7.2 the
lists and are independent, and each has
entries, hence each is a basis (Theorem 1.6.4). By
Theorem 2.1.5 there is
a unique linear
with for all ; its image is (Theorem 2.2.4), so it
is surjective and hence an isomorphism (Corollary 2.3.2 (e)).
Thus carries
to .
If does too,
then , so with , that is, for every . Two linear maps
agreeing on a basis are equal (Theorem 2.1.5), so
and .
So the theorem to remember is Theorem 22.7.5, with the
count that
works over every field; is the one field
where a smaller count also works, for the accidental
reason that it has no scalars to spare.
Quick check. Exhibit two different
projectivities of that agree on
, and , and name a point
where they disagree.
Solution. Take and with . Both
fix the three coordinate points. They differ at , which sends to ; and ,
since is
not a scalar multiple of . By Theorem 22.7.3 (a) the
two projectivities are different, because is not a scalar
multiple of .
The
cross-ratio
Three distinct points on a projective line can be
moved to any other three, by Theorem 22.7.5 with . A fourth point
cannot: the theorem has used up all its freedom. What is
left over is one invariant, and it is a point of .
Definition
22.7.3 (Cross-Ratio)
Let be a
projective line, that is, a projective space of
dimension over
, let be
pairwise distinct, and let be arbitrary. Let
be the unique projectivity with The cross-ratio of the
ordered quadruple is the point
The projectivity exists and is unique
because three pairwise distinct points of a line are in
general position (Definition 22.7.2 with
), on both
sides. The cross-ratio is a point of , not a
scalar; in the chart it becomes a scalar whenever , and the one
excluded value, , occurs exactly
when , since
is injective.
Likewise exactly when , and exactly when .
A formula makes this computable.
Idea. Since , the pair is a
basis of , so the
expansions exist. The projectivity of Definition 22.7.3 is the
one induced by the linear map sending and , because that map sends to —
this is Lemma 22.7.4 for , done by hand. Then
evaluate it at . For the chart
formula, take , and solve two systems.
Proof. The points give independent
representatives (Definition 22.7.2), and
, so
is a basis of (Theorem 1.6.4) and
the expansions exist and are unique. If then ,
so ; if then . Both are excluded,
so .
Let be the linear map with and (Theorem 2.1.5; is a basis since ). Its image
is (Theorem 2.2.4), so it
is surjective, hence an isomorphism by Corollary 2.3.2 (e).
Then and . By the uniqueness in Theorem 22.7.5, is the map of Definition 22.7.3.
Finally and multiplying both entries by gives .
For the chart formula take , , , ; these
are representatives of the four points, and because . Solving , gives and the same computation with in place of gives , . Hence and clearing the common factor and the common
sign gives , as claimed.
Quick check. Proposition 22.7.8
insists that ,
and be pairwise distinct,
but puts no condition at all on . Where in the proof is
each of these used, and why is a
point of
for every ?
Solution. makes
independent, hence a basis, which is what lets and be expanded at
all. and
are what
force and
, which is
what makes a basis and lets us divide by
and . For nothing is needed:
, so , and since the pair
is
again not . So
it names a point of , whichever point
is.
Theorem
22.7.9 (Invariance and Completeness of the
Cross-Ratio)
Let and be projective
lines over .
- (a)
(Invariance) If is
a projectivity and are pairwise distinct, then for every
, .
- (b)
(Completeness) Let be pairwise
distinct and pairwise distinct, and let
, . Then
there is a projectivity carrying to if and only if .
Idea. Both halves come from the
uniqueness in Theorem 22.7.5, with no
computation. For (a), normalizes the image triple, so it
is the normalizing map of that triple;
evaluate it at . For (b), let be the unique
projectivity matching the triples; by (a) it preserves
the cross-ratio, and the cross-ratio determines the
fourth point because the normalizing map is
injective.
Proof.
(a) Let
be the projectivity of Definition 22.7.3 for
. Since
is a bijection
(Proposition 22.7.1),
are pairwise distinct, so the corresponding map exists. The composition is a projectivity (Proposition 22.7.1) and
sends , , . By the uniqueness in Theorem 22.7.5, .
Hence
(b) is (a).
Let
be the unique projectivity with , , (Theorem 22.7.5, ). Let be the normalizing
map for . By (a), Since is injective,
. This
proves the theorem.
So four points on a line carry exactly one piece of
data that survives every projectivity, and two
quadruples are projectively equivalent precisely when
that datum agrees.
Example
(A cross-ratio, before and after)
On ,
use the chart and take the points with parameters
, , , . Compute . Then apply
the projectivity with and compute the
cross-ratio of the images.
Solution. By Proposition 22.7.8, which is the scalar in the chart.
The matrix
has , so
is a projectivity. It sends to , which
lies in the chart when and is then the scalar . The four
parameters become The images are not equally spaced in any
sense, and the gaps have changed from to . The cross-ratio, however, is after multiplying both entries by . This is Theorem 22.7.9 (a) in one
instance.
As a second check, run Proposition 22.7.8 in its
first form with and : solving gives and
, so .
Warning. The cross-ratio
depends on the order of the four points. It is
a function of an ordered quadruple.
Swapping the first two points inverts it: with the
notation of Proposition 22.7.8, , the two entries exchanged. With
as above, while
,
and .
Writing “the cross-ratio of four points” without fixing
an order names six different values in general.
Perspectivities
The classical source of projectivities is projection
from a point, and it is worth seeing that the synthetic
construction is the linear-algebraic one.
Proposition
22.7.10 (Projection From a Point Is a
Projectivity)
Let ,
let and
be lines in the projective plane
, and let
be a
point lying on neither. For , let be the unique
point in which the line meets . Then
is well defined, and it is the projectivity induced by
the restriction to of the projection of
onto along . In
particular
preserves cross-ratio.
Idea. Everything is forced by
dimensions in a -dimensional . Since
and , we have , so every vector
splits uniquely as “a piece in plus a multiple of
”. Throwing
away the multiple of is a linear map,
and on it is
injective because . That map is the projection, and the
line is
exactly where the discarded multiple of lives.
Proof. Since and
, the sum
properly contains , so its dimension
exceeds and it
equals . Since
, the sum is direct by Theorem 1.7.4, so
. Let be
the projection onto along (Theorem 4.5.1
(b)), so that is the unique such splitting, and is linear.
The restriction is an
isomorphism. If and , then ; since , this
forces and . So is injective, and
makes it an isomorphism (Corollary 2.3.2
(e)).
. Let with . Since , the vector is not a
multiple of , so
has dimension .
The projective subspace contains and , and any projective
subspace
containing both has ,
hence ; so , a line. Now , and ,
so lies
on both
and . These
two lines are distinct, because lies on the first and
not on the second, so by Theorem 1.7.3, the
sum being all of
since it properly contains . Hence the
intersection point is unique and equals . So is well defined and
, a
projectivity. Cross-ratio invariance is Theorem 22.7.9 (a).
The two lines need not be distinct. If , then for
the line
is not
, because lies on the first and
not on the second, so the two meet in exactly one point
(Corollary 22.6.7) and
that point is :
the construction gives . The classical statement takes the lines
distinct, but the proof above never uses it.
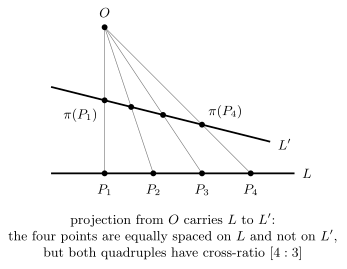
Informally, this is what a photograph does. As a
physical model rather than a theorem: a camera records,
for each point of the scene, the point where the line
from that point to the lens meets the film, and along
any one line of the scene that is exactly the map . So a photograph of a
straight railway track distorts the spacing of the
sleepers but not their cross-ratio. Four equally spaced
sleepers, with parameters along the track, have cross-ratio and the four images on the film, bunched ever
closer together toward the horizon, have cross-ratio
as well.
Equal spacing is not a projective notion; is.
Affine
maps inside the projective group
The chapter began with affine geometry, and we can
now say exactly how it sits inside projective geometry.
By Theorem 22.6.2, is the disjoint
union of the chart , identified with affine -space by and the hyperplane at infinity .
Theorem
22.7.11 (Affine Maps Are the Projectivities
Fixing Infinity)
Let and
let be a
projectivity of . Then if and only if for a matrix of
the block form In that case maps the chart onto
itself, and in the affine coordinates above it acts as
an invertible affine map with linear part
(Definition 22.1.3, Theorem 22.1.5).
Conversely every invertible affine map of arises from exactly
one such .
Idea. “ fixes as a set” says
that the matrix maps into itself, which is a statement
about the top entry of columns. Invertibility
then forces the remaining corner entry to be nonzero,
and since a projectivity only knows its matrix up to a
scalar, we may divide by that entry. What is left is the
block matrix that Section 01 already introduced for
affine maps — the same matrix, with the extra coordinate
moved from last place to first.
Proof. Write , so , and let with .
Suppose . By Proposition 22.7.2, , and
hence : a
nonzero has , so , and
conversely. Thus for
,
which says the columns of have zero entry in row
. Writing column
as with and , and the
lower right block as , Here
is invertible:
restricts to an injective map , which is
therefore surjective (Corollary 2.3.2 (e)),
and that restriction is in the basis of . And : if then column of lies in , so
for some , and injectivity would give , which
is false. Replacing by , which by Theorem 22.7.3 (a)
induces the same projectivity, puts in the stated form
with in the
corner.
For
of the stated
form and , the first entry of is where collects
the last entries,
so ; and
is invertible, since
forces and
then , so .
By Corollary 2.3.2 (e)
again , and
Proposition 22.7.2 gives
.
The action on the chart. Since is a bijection of mapping onto , it maps the
complement onto itself. A point of the chart is with , and
whose affine coordinates are . By
Theorem 22.1.5 this is
the affine map with linear part and value at the origin,
and it is invertible because is.
Converse. Given an invertible affine map
of , the matrix displayed
above induces a projectivity fixing and
restricting to it. If two such matrices , induce the same
projectivity, then by Theorem 22.7.3 (a), and
comparing the corner entries gives , so . This proves
the theorem.
So the affine group of is the subgroup of
stabilizing one hyperplane. Projective geometry is
affine geometry with the hyperplane at infinity
forgotten, and every affine notion that a projectivity
can destroy — parallelism, ratios of lengths along a
line, midpoints — is a notion that mentions . The
cross-ratio never does, which is why it survives.
Exercises
A. Check your
understanding
Solution.
(a) Exactly when
for
some (Theorem 22.7.3
(a)).
(b) points in general
position, that is, points of which every
have linearly
independent representatives (Definition 22.7.2, Theorem 22.7.5).
(c) True. Here
, so four
points in general position are points in general
position. The identity is one projectivity fixing them,
and by the uniqueness in Theorem 22.7.5 it is the
only one.
(d) False. The
matrices and
induce the
same projectivity but have determinants and .
(e) . By
Definition 22.7.3 the
cross-ratio is
with , and
by the
definition of .
B. Practice
Solution. The source triple is
already normalized in the sense of Lemma 22.7.4:
is a basis and . Normalize the target:
we need , that is,
and . Subtracting, , then . Both are
nonzero, as Lemma 22.7.4
guarantees.
So the map sends
and , that is, Check: , so
; , so ; , so . By
Theorem 22.7.5 no other
projectivity does this, so every other correct answer is
.
Solution. Here , so general
position for four points means every triple of
representatives is independent, tested by a
determinant.
(a) The four
determinants, in the order of the triples , , , , are The third is zero, so the list is
not in general position: , , are collinear,
since .
(b) Not in
general position: , so the first three points
are collinear.
(c) In general
position. The four representatives are for , so each
triple gives a Vandermonde matrix, whose determinant is
(Theorem 7.8.1, and Corollary 7.8.2 for
the conclusion). Explicitly, gives ;
gives
; gives ; gives . All are nonzero, so every triple
is independent.
Solution.
(a) By Proposition 22.7.8,
(b) The matrix
has determinant ,
and sends
to , which
in the chart is . The four
parameters become . Then so the cross-ratio is , after multiplying
both entries by . This agrees with
(a), as Theorem 22.7.9 (a)
requires.
C. Going deeper
Solution.
(a) On a line,
, so and general
position for three points means pairwise distinct (Definition 22.7.2). The
statement is Theorem 22.7.5.
(b) By (a),
acts on the set of ordered triples of pairwise distinct
points of in such a
way that exactly one group element carries any given
triple to any other. Fixing one triple, the map is therefore a bijection from
onto the set of such triples. Now has points: there are
nonzero
vectors in ,
and each point has exactly representatives, so the count is .
Hence For
this is . And indeed has the
three points ,
, ; by (a) every
permutation of them is realized by exactly one
projectivity, giving . (Consistently, has elements and the
scalars are only , so of Theorem 22.7.3 is
injective here.)
Solution.
(a) Use Proposition 22.7.8 with
the representatives and
the expansions , . Computing means
expanding in the basis
instead, which exchanges the roles of the two
coordinates: the coefficients of are now and those of
are . The formula
gives , the entries of
exchanged.
(b) By Proposition 22.7.8 in the
chart, Put both over the common denominator , noting : Expand the numerator: Hence , as claimed.
Solution. Write with and pick a
basis of ; the three points , ,
are pairwise distinct, since no two of are proportional. So we may choose
pairwise distinct . Since is injective, are
pairwise distinct. By Theorem 22.7.5 with there is a unique
projectivity with , , .
Let . By
the hypothesis on
and by Theorem 22.7.9 (a)
applied to , The two triples on the outside are the same,
namely . Writing for the
normalizing projectivity of that triple (Definition 22.7.3), the
displayed equality reads , and is injective, so
. As
was arbitrary,
, a
projectivity.
Note where each hypothesis went: injectivity of was needed only to make
distinct, so that the cross-ratio hypothesis is
applicable at all. Surjectivity was never assumed, and
comes out at the end: and is
a bijection (Proposition 22.7.1).