Sections 01 and 02 looked at a convex set from the
inside: which combinations of its points it contains,
and how few points a combination needs. This section
looks at it from the outside. A point that is not in a
closed convex set can be cut off from it by a
hyperplane, a set can be touched at its edge by a
hyperplane that leaves the whole set on one side, and
two disjoint convex sets can be pulled apart by one. All
three facts come from a single construction, the point
of the set nearest to a given point, and that
construction is Chapter 11’s orthogonal projection with
the subspace replaced by a convex set.
Throughout, is a finite-dimensional
real inner product space, with inner product
(Definition 11.1.1),
induced norm (Definition 11.1.3),
and . A
sequence converges, ,
when ; closed means
closed in the sense of Definition 18.1.6, so
that a closed set contains the limit of every convergent
sequence of its points. A set is
compact if every sequence in it has a
subsequence converging to a point of the set; this is
the word of Corollary 16.2.5, which says
that every closed bounded subset of is compact. The field
is because the
whole section is about inequalities.
The
nearest point of a closed convex set
Chapter 11 answered a question about subspaces: given
and a
finite-dimensional subspace , which vector of is closest to ? Theorem 11.3.5 said
there is exactly one, the orthogonal projection , and that
is perpendicular to . Now replace by a set with less
structure, such as a disc, a box, or a half-plane, and
ask the same question. Two small experiments in show which
hypotheses the answer needs.
- The open disc and the point . The
points
of the disc come closer and closer to , but the
distance is never
reached, since the only candidate is missing. There
is no nearest point. The set is convex but not
closed.
- The circle and the point .
Every point of the circle is at distance , so every point is a
nearest point. The set is closed but not convex.
So we ask for both properties, and then everything
works.
Theorem
18.3.1 (Nearest Point Theorem)
Let be a
nonempty, closed, convex subset of
, and let .
The nearest point is written , and the
map is the projection onto . The number
is the
distance from to .
Idea. Three jobs, three tools. ①
Existence: a nearest point is a minimum of the
continuous function , and a
minimum exists on a compact set; itself may be
unbounded, so cut it down to the part of within a fixed distance
of . ② The
inequality Eq. 18.3.1 is the
first-order condition: slide from a little way
towards another point of , which convexity
allows, and ask that the distance not decrease. ③ Read
backwards, the inequality says that the angle at between and
is at least a right angle, and expanding then gives . That inequality proves both that
is nearest
and that nothing else is.
Proof. Existence. Since
,
pick and put . Let Then , and is bounded, since for by Corollary 11.1.6.
It is closed: if and ,
then
because is
closed, and for every ; the right-hand side
tends to , and a
nonstrict inequality survives a limit, so . By Corollary 16.2.5, the form
in which Chapter 16 carried the compactness of
closed bounded sets, fact (A3) of Chapter 16’s
introduction, over to every finite-dimensional
space, is
compact. The function is continuous, since by Lemma 16.1.1. By the
extreme value theorem, fact (A4) of Chapter 16’s
introduction, attains a minimum on
at some . Every
has . So for every .
(b), . Let
be a
nearest point and let . For , the point
lies in
by Definition 18.1.1.
Hence, expanding with Theorem 11.1.2 (c)
over , Cancel and divide by : . This
holds for every , and letting gives Eq. 18.3.1.
(b), , and
uniqueness. Let satisfy Eq. 18.3.1, and let
. The
same expansion with gives So , and
is a
nearest point. Finally, the nearest point found in the
existence step satisfies Eq. 18.3.1 by , so applies to it; for
with
it gives ,
and is not
a nearest point. This proves the theorem.
The inequality is Pythagoras with
the equality relaxed to an inequality. That is exactly
the relation with Chapter 11, and it deserves to be said
precisely.
This theorem generalizes Theorem 11.3.5.
Let be a
subspace of . It
is convex, and closed by Proposition 18.1.6 (c).
For ,
the vector runs over all of
as does, and with
each
it also takes the value . So Eq. 18.3.1 says and , that is, For a subspace the variational
inequality becomes an equality, the statement
. Then is the splitting of Theorem 11.3.2 (a),
so by Definition 11.3.2,
and becomes
the equation of Theorem 11.1.3 used
in the proof of Theorem 11.3.5. The
projection onto a closed convex set is the orthogonal
projection with “perpendicular” weakened to “at an
obtuse angle”.
Example
(Three projections)
Find in each
case, and check Eq. 18.3.1.
- (a) is the closed unit ball
of , and .
- (b) is the box with the
dot product, and .
- (c) is the half-space , where ,
and .
Solution.
(a) . With we have and
, so for because and by Theorem 11.1.5. By
Theorem 18.3.1 (b),
is the
nearest point, and .
(b) Clamp each
coordinate into : . Then and, for , since , , and . So and . The vector also cuts off: and , so
, and the plane
strictly separates from , since its left
side is at most on and
equals at . Theorem 18.3.2 below
turns this recipe into a theorem.
(c) Put , which is positive, and
. Then , so , and for So : drop the
perpendicular to the boundary hyperplane, as Chapter 11
would have done. The distance is .
Two degenerate cases fix the scale. If is a
single point, then
for every ,
and Eq. 18.3.1 holds because
. If , then is the identity. In
every case exactly when .
Quick check. Where did the proof of
Theorem 18.3.1 use that
is closed, and
where that it is convex? Match each use with one of the
two failing experiments before the theorem.
Solution. Closedness was used in
the existence step, to make closed and hence
compact; the open disc fails there, since the minimizing
candidates converge to a point outside it. Convexity was
used in , to know
that , and uniqueness rests on that
step. The circle fails there: with ,
, and ,
.
Warning. The proof needs an
inner product, and uniqueness can fail without
one. In with , let
be the -axis, which is closed
and convex, and . Then for every , so there
is a whole segment of nearest points. Existence
survives, since its proof used only (N3) and
compactness. Uniqueness does not, because it came from
the expansion of , which is available only for
induced norms.
Hyperplanes and half-spaces
A hyperplane in the sense of Chapter 5 passes through
: it is a
subspace of codimension (Definition 5.5.2). To
separate sets we need translates of hyperplanes, and
Chapter 5 §06 called a coset of a
hyperplane (Definition 4.4.2)
an affine hyperplane. In an inner
product space these have a concrete form. By Theorem 5.5.3, for a
nonzero ; by Theorem 11.5.1,
for a nonzero . Hence
and conversely every such set with is
an affine hyperplane, with as a
normal vector. It cuts into the two
closed half-spaces and . Both are convex, because
is linear, and closed by Proposition 18.1.6
(c).
Definition
18.3.1 (Separation by a Hyperplane)
Let be nonempty. A nonzero
vector and a number separate and if They strictly separate and if in addition there is
a real with and for all , .
In words: lies
in one closed half-space of and
in the other, and strict separation puts a slab of width
between them. Replacing by swaps the
roles of and
. With and
any two sets
would be “separated”.
Cutting
off a point
The first consequence of Theorem 18.3.1 is the
one the chapter uses most. If is not in , the vector from to is a normal
vector for a hyperplane that cuts off.
Theorem
18.3.2 (Separating a Point from a Closed Convex
Set)
Let be nonempty, closed, and convex, and let
.
Put . Then and
In particular and strictly separate
and .
Proof. Write .
Since and , . For , Eq. 18.3.1 gives , hence With this reads
, while . This proves the theorem.
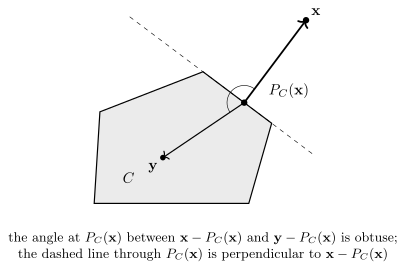
In the picture after Theorem 18.3.1, the
hyperplane of the theorem is the line parallel to the
dashed one, halfway between and .
The theorem turns into a description of a closed
convex set from the outside. Sections 01 and 02 built
convex sets up from points; this builds them down from
half-spaces.
Corollary
18.3.3 (A Closed Convex Set Is an Intersection
of Half-Spaces)
Every nonempty closed convex subset of is the intersection of
all the closed half-spaces , with ,
that contain .
Proof. Each of these half-spaces
contains , so
lies in their
intersection. Conversely, let . By Theorem 18.3.2, with
, the half-space
contains but not . So is not in the
intersection. (If , the family of half-spaces is empty and its
intersection is
by convention.)
The corollary has a converse that is immediate: an
intersection of closed half-spaces is closed and convex,
because each half-space is and both properties pass to
intersections. So the closed convex sets are
exactly the intersections of closed
half-spaces. §04 turns this into a formula, the support
function, and §09 studies the case of finitely many
half-spaces.
Supporting
hyperplanes
A point on the edge of cannot be cut off,
because it belongs to . The best one can hope
for is a hyperplane through the point with all of on one side, touching
without cutting
it. To say “on the edge” we need two more words.
Definition
18.3.2 (Interior Point, Closure, Boundary
Point)
Let . A point is an interior point of
if there is a
real such
that every with lies in ; the set of interior
points is written . The
closure of is the set of limits of
all convergent sequences of points of . A boundary
point of
is a point of that is not
an interior point of .
Constant sequences show , and by Definition 18.1.6, is closed exactly when
. By
Theorem 16.2.2 neither
notion depends on the norm used: a ball of radius for one norm contains a
ball of positive radius for any other. For the closed
unit disc of ,
the interior points are those with ,
and the boundary points form the unit circle. A segment
in has no
interior points at all, so every one of its points is a
boundary point; that is the case the next lemma
isolates.
Lemma
18.3.4 (A Convex Set Is Solid or Flat)
Let and let be nonempty
and convex. Then either has an interior point,
or lies in an affine
hyperplane: there are and
with
for every .
Idea. Fix and look
at the directions available inside . If they span a proper
subspace, a normal vector to that subspace is the we want. If they
span , then contains points in general
position, hence the solid simplex they span, and the
center of a solid simplex is an interior point: a point
of the simplex is with summing to , the are determined by the
point and depend continuously on it, and at the center
they are all equal and positive, so every small enough
move keeps them positive.
Proof. Fix and let
.
Case 1: . Then , so by Theorem 11.3.2 (c),
and there is in . For , , that is, . Take .
Case 2: . Choose a linearly independent list
with every
and as large as
possible;
by Theorem 1.6.3. Every
vector with lies in
the span of this list, since otherwise Lemma 1.5.3 would
lengthen it. So the span contains every generator of
, hence equals
, and the list is
a basis; thus . Let be
the -th coordinate
of in this
basis, a linear functional by Theorem 1.5.2, and
write by Theorem 11.5.1. Put
. Then for
every , and when for
every and , this is a convex combination of points of
, hence a point of
: by Theorem 18.1.3 it lies
in , and
by Definition 18.1.4, since
is itself a
convex set containing .
Let , so that for every . Each ,
because ; put and . If , then by Theorem 11.1.5
so
and . Hence
, and
is an
interior point of .
The second ingredient says that from an interior
point one can see the whole closure.
Lemma
18.3.5 (Closure and Interior of a Convex
Set)
Let be convex.
- (a) is closed and
convex.
- (b) If , ,
and ,
then .
Idea. Part (a) pushes limits
through: a limit of limits is a limit, and a convex
combination of limits is the limit of convex
combinations. For (b), picture a small ball around inside , and the cone from
over it.
The cone contains a smaller ball around ; since is only a limit,
replace it by a nearby point of , which shrinks the ball
by half.
Proof.
(a) Let with .
Each is
a limit of points of , so there is with
. Then , so
. For convexity, let
and with , and . The points lie in and converge to , by Corollary 11.1.6,
so that point lies in .
(b) Take with every
point within distance of in , and put . If then and there is nothing to prove, so let
. Choose
with , possible because
is a limit
of points of . Let
, and put , so that . Since , Hence , and
by
Definition 18.1.1. So
every point within of lies in , and .
Now the theorem. It asks only that not be an
interior point, which covers the boundary points of
and also the
points outside .
Theorem
18.3.6 (Supporting Hyperplane Theorem)
Let , let be convex, and let be a
point that is not an interior point of
. Then there is a
nonzero with If moreover , the
affine hyperplane passes through
and has
in one of its
closed half-spaces; it is called a supporting
hyperplane of at .
Idea. Approach from outside
and cut
off each approximating point with Theorem 18.3.2. The
normal vectors, scaled to length , live on the compact
unit sphere, so a subsequence converges, and in the
limit the strict inequalities become the nonstrict one
we want. The only thing that could go wrong is that
there are no points outside near . Lemma 18.3.4 and Lemma 18.3.5 rule that
out: if is flat,
its own hyperplane serves; if is solid, pushing directly away
from an interior point leaves at once.
Proof. If , any
nonzero
works, and one exists because . So
let .
Case 1:
has no interior point. By Lemma 18.3.4 there are
and with for all . If , then works. Otherwise
works,
since .
Case 2:
has an interior point . For let . We claim . Indeed, with , so if were in , then would be an
interior point of
by Lemma 18.3.5 (b),
contrary to the hypothesis. By Lemma 18.3.5 (a), is nonempty,
closed, and convex, so Theorem 18.3.2, applied
to and
, gives
with for all ,
in particular for all . Put , a unit vector
satisfying the same inequality.
The unit sphere of is compact by Corollary 16.2.5, which
rests on fact (A3) of Chapter 16’s
introduction. So a subsequence
converges to some with ; in
particular . Fix . Then
for every , and
because .
By Theorem 11.1.5,
which tends to . A nonstrict inequality
survives the limit, so . This proves the theorem.
A supporting hyperplane need not be unique. At the
corner of
the square , every
with , not both zero, works, since on the square. At a point of the unit
circle, the boundary of the disc, only the positive
multiples of the point itself work. Corners admit many
supporting hyperplanes and smooth points one; §08 builds
its induction on dimension on these hyperplanes, and §04
uses them to prove that a norm is recovered from its
dual.
Separating
two convex sets
To separate two sets, separate one point from one
set: the point from the set of
differences.
Theorem
18.3.7 (Separating Hyperplane Theorem)
Let be nonempty, disjoint, and
convex.
- (a) If is
compact and is
closed, then and are strictly
separated: there are and
with for all , , and
indeed with a margin as in
Definition 18.3.1.
- (b) In general,
and are separated: there
are and with for all , .
Idea. The difference set is convex
and misses , and a normal
with on its positive side
separates from
. For (a),
compactness of
makes closed, and
Theorem 18.3.2 cuts
off; for
(b), is
not an interior point of , and Theorem 18.3.6
applies.
Proof. Let . It is
convex: for , a difference of a point of and a point of . And , since
.
(a) We show is closed. Let with , . Since
is compact, a
subsequence converges
to some . Then , since a subsequence of a convergent
sequence has the same limit, part of the elementary
algebra of limits that Chapter 16’s introduction
imports; so because is closed, and . Now Theorem 18.3.2, applied
to and the point
,
gives with for all . With
this says Fix . The numbers ,
,
are bounded above by , so by the
completeness of , fact (A1) of Chapter
16’s introduction, they have a least upper
bound , and for every . Take
and . Then
and .
(b) If , two
nonempty subsets both contain and cannot be
disjoint, so . The point is not in , so it is not an
interior point of . By Theorem 18.3.6 there is
with for all . With
, this says for all , . As in
(a), the least upper bound of the numbers ,
,
exists by (A1) and satisfies . This proves the
theorem.
Where
strict separation fails
Part (a) asked one of the two sets to be compact.
That hypothesis cannot be weakened to “closed”, and the
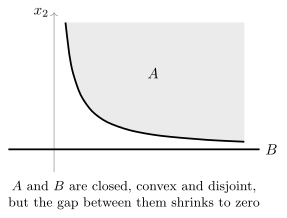
standard witness is a hyperbola and its asymptote.
Example
(A hyperbola and its asymptote)
In with
the dot product, let Show that and are nonempty, disjoint,
closed, and convex, that the -axis is the
only hyperplane separating them, and
that they are not strictly
separated.
Solution. Nonempty and
disjoint. and ; every point of has , and every
point of has
.
is closed
and convex. It is a subspace, so it is convex, and
closed by Proposition 18.1.6
(c).
is
convex. Let and , and let
. Its coordinates are positive.
Expanding, By , we get , using and . Hence , and .
is
closed. If with , then
the coordinates converge, so , and
by the algebra of limits, so . A product
that is at least
has no zero factor, so , and .
The only separating hyperplane. Let and
separate and , in either order. On
, for all real , and these values lie
on one side of ;
that forces . So , and after replacing by we may
take . On
the value is
. On the values are , and since for every
, they fill
the interval . These are unbounded above, so is on the side and on the side : for
every ,
which forces .
The hyperplane is the -axis, and it
separates, since on and
on .
No strict separation. Strict separation
would need the only separating hyperplane to miss both
sets, and
is that hyperplane.
The points and are
apart, and Exercise (C2: Strict separation and distance)
shows that this vanishing distance is exactly what rules
out strict separation.
Warning. Disjoint closed
convex sets need not be strictly separated. The
hyperbola region and its asymptote above are the example
to remember: both closed, both convex, disjoint, and
every hyperplane that separates them contains one of
them. “Disjoint” gives only the weak separation of Theorem 18.3.7 (b).
Strict separation needs more, such as compactness of one
set in (a).
Extending
linear functionals
Separation has an analytic twin. Instead of a set and
a point, take a linear functional defined on a subspace
and bounded there by a convex function; can it be
extended to the whole space without breaking the bound?
The bounds allowed are the following.
Definition
18.3.3 (Sublinear Functional)
Let be a real
vector space. A function is sublinear
if, for all
and all real ,
Every norm is sublinear: (N3) is the first condition,
and (N2) with the second. Every linear functional is
sublinear, with equality in the first condition. So is
on , which is neither a
norm nor linear: .
Taking gives
. A
nonexample by minimal change is : the first condition fails at
(it would give ), and so does the second,
since .
It turns out that sublinearity is exactly what makes
one-step extensions possible.
Theorem
18.3.8 (Hahn–Banach Theorem,
Finite-Dimensional)
Let be a
finite-dimensional real vector space,
let be a
sublinear functional on , let be a subspace of , and let satisfy for every . Then
there is with
Idea. Add one dimension at a time.
On , a linear extension is fixed by
one number . The requirement at the vectors
with gives upper bounds on , and at those with
it gives
lower bounds. Sublinearity of , together with
linearity of , is
exactly what makes every lower bound at most every upper
bound, so some
fits. Then induct on . No inner product is needed.
Proof. We induct on . If
, then and works.
Let and
assume the theorem whenever the difference of dimensions
is . Pick
and let . Each can be
written as with and , and only in
one way: if with
, then
, which is false;
so and
. Appending to a basis of
gives a basis of
by Lemma 1.5.3, so
. For , the formula therefore defines a linear
functional on
that extends .
For , linearity of , the hypothesis, and
sublinearity of
give that is, . So every number in is at most every
number in . By fact (A1) of
Chapter 16’s introduction, the nonempty set
, bounded above by
any element of ,
has a least upper bound , and for every . With this , we check in three cases.
- : this is
the hypothesis .
- : , the element of at . Multiply by and use : .
- :
, since this is an
element of .
Multiply by :
, that is, .
So on
. By the induction
hypothesis applied to and , there is extending
, hence , with on . This proves the
theorem.
Beyond finite dimension. The
induction above stops after steps. In
an infinite-dimensional space there is no last step, and
the one-step extension has to be combined with Zorn’s
lemma (Theorem 1.8.1),
exactly as Chapter 1 §08 combined “append one vector”
with Zorn’s lemma to prove Theorem 1.8.3. The
resulting theorem, the Hahn–Banach theorem of functional
analysis, is outside the scope of this book, and nothing
here depends on it.
The special case that matters most is a norm.
Corollary
18.3.9 (Norm-Preserving Extension)
Let be a
finite-dimensional real vector space with a norm , let be a subspace, and let
satisfy
for every . Then
there is extending with for every .
Proof. A norm is sublinear, so Theorem 18.3.8 with
gives extending
with for all . Applying this
to gives
by (N2).
Hence .
In particular, for any ,
taking and produces a functional with and everywhere: a linear functional
that “sees” the full length of without ever
exceeding the norm. §04 meets this functional again, as
the vector at which a dual norm is attained.
Example
(Many extensions)
On with
, let
and .
Find every as in
Corollary 18.3.9, and
compare with the interval produced by the proof of Theorem 18.3.8 for .
Solution. First, , so the
hypothesis holds. An extension has for
some , and then
, so .
If , then . If , then gives
. If , then gives
. So the extensions are exactly with : infinitely many.
In the proof, with , and
, the elements of are , which is for and for ; so . The elements
of are , which is for and for ; so
. Every
between and works, and that is
the interval
found directly. The proof picked its left end.
The corners of the square are why the
extension is not unique: meets the unit sphere
at the corner , and every supporting line of the square at
that corner gives an extension.
Exercises
A. Check your
understanding
Exercise
(A1)
- (a) State the
characterization Eq. 18.3.1 of the
nearest point, and say what it becomes when is a subspace.
- (b) Which two facts
of Chapter 16’s introduction does the existence of use, and to
which set are they applied?
- (c) Determine
whether the following statement is correct, and justify
your answer: every nonempty closed subset of has a unique point
nearest to .
- (d) Determine
whether the following statement is correct, and justify
your answer: two disjoint nonempty closed convex subsets
of can always
be strictly separated.
Solution.
(a) A point is exactly
when for every
(Theorem 18.3.1 (b)). For
a subspace it
becomes the equality for every , so and Theorem 11.3.5 is
recovered.
(b) The
compactness of closed bounded sets (A3), through Corollary 16.2.5, and the
extreme value theorem (A4). They are applied to , the part of
within the
distance of attained at one
chosen point of ,
and to the function .
(c) Incorrect.
The unit circle is closed and nonempty, and every one of
its points is at distance from . Uniqueness
needs convexity.
(d) Incorrect.
The region above
the hyperbola in the positive quadrant and its asymptote
, the -axis, are disjoint,
closed, and convex, but the only hyperplane separating
them is itself
(Example (A hyperbola and its asymptote)).
B. Practice
Exercise
(B1: Projection onto a half-plane)
In with
the dot product, let and . Find
and
, and
verify Eq. 18.3.1.
Solution. Here , , and . By Example (Three projections)
(c), and . Check: , so ,
and , so for . By Theorem 18.3.1 (b) this
is the nearest point, and .
Exercise
(B2: Cutting off a point from a diamond)
Let , with the dot product, and .
- (a) Show that .
- (b) Hence find the
strictly separating hyperplane of Theorem 18.3.2, and
check it directly.
- (c) Find every
supporting hyperplane of at .
Solution.
(a) Let , which lies in . Then and, for , because .
By Theorem 18.3.1 (b),
.
(b) With , we have and , so . The hyperplane is the line .
Directly: on ,
, while .
(c) Let
satisfy for all . Taking
and
gives and , that is, and ; so . Taking
gives ,
so , and
since
. Conversely with
works, by
the inequality in (a). So the only supporting hyperplane
at is the
line
through the edge containing .
Exercise
(B3: A unique extension)
On with
, let
and . Show that satisfies the
hypothesis of Corollary 18.3.9, and
find every extension that the corollary
allows.
Solution. , so the hypothesis holds. Every
is (Theorem 5.1.1), and it
extends exactly
when , that is, .
Next, for all
holds
exactly when and .
Indeed, if both hold then ; and if,
say, , then gives .
So we need with and .
The first gives , the second ; hence and . The only
extension is .
C. Going deeper
Exercise
(C1: The projection does not stretch)
Let be nonempty, closed, and convex. Prove that
for all .
Hint: write Eq. 18.3.1 once at , tested with the
point , and once
at , tested
with ,
and add.
Solution. Put
and . By Theorem 18.3.1 (b),
applied at
with the point and at with the point
,
The second is . Adding,
, that is, by Theorem 11.1.5. If
there is nothing to prove; otherwise divide by . This proves .
Exercise
(C2: Strict separation and distance)
Let be nonempty, closed, and convex, and put
.
- (a) Prove that if
and are strictly
separated, then .
- (b) Prove that if
, then
and are strictly
separated.
- (c) Hence deduce,
without the computation of Example (A hyperbola and its asymptote),
that the sets and
there are not
strictly separated.
Hint for (b): replace the difference set of Theorem 18.3.7 by its
closure.
Solution.
(a) Let ,
, and
strictly separate the sets, with on the side . For
and , Theorem 11.1.5
gives so .
Hence .
(b) Let , which is
convex by the computation in the proof of Theorem 18.3.7. Every
has
, and so does every point of : if
with , then for every
, and the right
side tends to . So , and is nonempty,
closed, and convex by Lemma 18.3.5 (a). By Theorem 18.3.2 there is
with on .
With , this is for all , , and the
last paragraph of the proof of Theorem 18.3.7 (a) turns
it into strict separation with .
(c) The points
and
are at
distance , so
for
every , and
. By (a),
and are not strictly
separated.