We can now measure a single subspace: take a basis
and count. This section asks how two or more subspaces
combine. The intersection of two subspaces is again a
subspace, but the union usually is not, so we need a
better way to join them. The answer is the sum . We then prove the
dimension formula for sums and single out the best case,
the direct sum, in which every vector splits into pieces
in exactly one way.
The sum of
subspaces
Recall from Theorem 1.2.2 that
is a
subspace whenever
and are. It is
the largest subspace inside both. The natural companion
would be the smallest subspace containing both, and the
first guess is the union .
That guess fails. In , let be the -axis and the -axis. Then and , but their
sum lies on
neither axis, so is not closed under addition (Example (The Union of the Two Axes)).
In fact Proposition 1.2.3
shows that
is a subspace only in the dull case or .
The failure tells us what is missing. Any subspace
containing and
must contain
for every and , because subspaces are closed under addition.
So we put all these sums in from the start.
The sum of two subspaces is everything you can
reach by adding one vector from each.
Definition
1.7.1 (Sum of Subspaces)
Let be a
vector space over , and let and be subspaces of . The
sum of and is the subset More generally, for subspaces of (with ), their
sum is
In words: a vector lies in when there
exist some and some with . The definition asks for one such
pair. It does not say the pair is unique, and in general
it is not. For
subspaces we pick one vector from
each and add them. We also
write , and for the sum is just .
Here are some first examples.
- The two axes. In , with the -axis and the -axis, every equals , so . The union
is two lines; the sum is the whole plane.
- Two planes in . Let
and . Every is a sum of a vector in
and one in
, so .
- Polynomials. In , let be the constant
polynomials and . Then , so .
- Matrices. In , the upper
triangular matrices plus the lower triangular matrices
give everything:
- Degenerate cases. For any subspace
, we have and
. In both,
“” holds
because , and “” holds because
is closed under
addition. So adding a subspace to itself produces
nothing new: a sum is not a count.
Nonexample by minimal change. The
definition makes sense for any two subsets , but the
result need not be a subspace. Take and
in
. Then ,
which does not contain . What changed is
that and are not subspaces: the
hypothesis “subspace” is exactly what makes the next
theorem work.
Warning. The sum is
not the union . A vector of
need not lie
in or in : lies in the sum of
the two axes but on neither axis. Conversely, is usually far
bigger than .
The sum does what we built it to do.
Theorem
1.7.1 (Sum of Subspaces Theorem)
Let be subspaces of a vector space . Then is a
subspace of that
contains each .
Moreover, if is
any subspace of
containing every , then . In other words, is the
smallest subspace of containing .
Proof. Write . We
apply the Subspace Test (Theorem 1.2.1).
Each
contains ,
so .
Let and be in , with . Regrouping with (VS1) and (VS2), and because is closed under
addition. Hence
is closed under addition.
Let .
By the distributive axiom, , and
because is
closed under scaling. Hence is closed under scalar
multiplication.
Therefore is a
subspace. It contains : for , take
and for . Finally, let be a subspace
containing every . An element of is a sum of vectors
, so it lies in since is closed under
addition. This shows .
So the sum plays the role that the union could not.
It is the subspace analogue of , and the two
notions fit together exactly. Recall from Theorem 1.3.1 that
is the
smallest subspace containing .
Proposition
1.7.2 (Sum of Spans)
Let be finite lists of vectors in , and let be the list obtained by
writing one after another. Then
Proof. () The subspace
contains
every vector of each , so by Theorem 1.3.1 it
contains each . By Theorem 1.7.1 it
therefore contains .
() The
sum is a subspace by Theorem 1.7.1, and
it contains each , hence every
vector of . By Theorem 1.3.1 it
contains .
In practice this means: to find a spanning
list of a sum, concatenate spanning lists of the
summands. That list may be dependent, and the
dimension formula below tells us by how much.
Quick check. In , what is ? Is it equal to ?
Solution. By Proposition 1.7.2
the sum is ,
the -plane. It is
not the union: lies in the plane but on neither axis.
If and are finite-dimensional,
how big is ?
Concatenating a basis of and a basis of gives a spanning list
of of length
(Proposition 1.7.2).
That count is too large when and overlap. For the two
planes and
in , it would give
, but
has dimension . The overlap is the
-axis, of
dimension , and it
has been counted twice. The theorem says this is the
whole story.
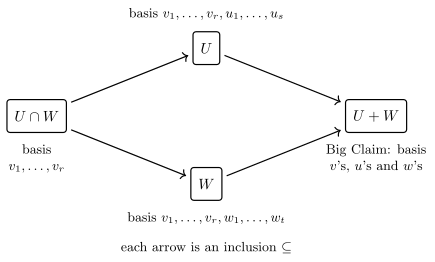
The picture behind the proof is the inclusion
diagram. The smallest space, , sits inside
both and , and both sit inside
. We build
bases from the bottom up.
Idea. This is a dimension formula,
so we start from the smallest space and
extend outward.
① Take a basis of . ② Extend it to a basis of by adding , and separately to a basis of by adding . ③ Big Claim: the
combined list of all vectors is a basis of . Spanning is easy.
For independence, move the -part to the
other side: the common vector lies in and in , hence in , where the ’s are a basis. ④
Count: .
Proof. Step 1:
bases. By Theorem 1.2.2, is a subspace of
; it lies inside
and uses the same
operations, so it is also a subspace of . Since is finite-dimensional,
so is (Theorem 1.6.7), and
it has a basis , where (Corollary 1.5.5).
This list is independent and lies in , so by the Basis
Extension Theorem (Theorem 1.6.5) there
are vectors such that is a basis of
. In the same way,
since the list also lies in , there are such that is a basis of
. Thus and .
Step 2: the Big Claim.
Claim. The list is a basis of .
Proof. Spanning. By Proposition 1.7.2,
is the span of the concatenated list. That
list contains each twice;
removing the second copies does not change the span,
since every removed vector already lies in the span of
what remains (Theorem 1.3.5).
Hence spans
.
Independence. Let
satisfy Move the -part across and
name the common vector: The middle expression lies in , because all the and do. The
right-hand expression lies in , because all the do. Hence
. Since spans , there are
with .
Comparing with the right-hand expression for , This is a combination of the basis of , which is independent,
so all and
all .
Putting into the original equation leaves a combination of the basis of . By its independence,
all and all
. Hence
is linearly
independent (Definition 1.4.1).
Step 3: count. By the claim, has a finite basis
of length , so it is finite-dimensional with
(Definition 1.6.1).
Therefore as claimed.
The proof also works when some of are : an empty list is
independent and spans , and every
step reads correctly with empty sums. The move “basis of
the smallest space, extend, Big Claim, count” is worth
learning as a unit. It proves Rank–Nullity in Chapter 2
with the same four blocks.
The formula is often used to find one of the four
numbers from the other three. Here are two uses, one by
counting and one by computing.
Example
(Two planes in )
Let and . Show that , and find a basis of of the shape used
in the proof.
Solution. Solving for , every vector of is . The two vectors are independent
(look at the first and third entries), so . Similarly
every vector of
is , and .
A vector lies in when and , that is, . So , which
has dimension . By
the dimension formula, Since and the dimensions agree, by Theorem 1.6.8.
Following the proof: extends to a basis of by . Indeed
is not a
multiple of , since its first and third entries differ,
so the list is independent by Lemma 1.5.3; it has
length ,
so it is a basis of (Theorem 1.6.4). It
extends to a basis of by , for the
same reason: a multiple of with first
entry is . The Big Claim
says is a basis of .
Example
(Two planes in from spanning
lists)
Let and in . Find and , and hence a
basis of .
Solution. Each spanning list is
independent: in ,
both and are , and similarly . So .
A vector lies in exactly when it can be written in both forms,
. Comparing entries gives , , , , so . Hence
and . By the dimension formula, .
For a basis, follow the proof. The vector together
with
is a list in , and
it is independent by Lemma 1.5.3, because
a multiple of never equals . It has length , hence it is a
basis of (Theorem 1.6.4).
Likewise is a basis of . By the Big Claim,
is a basis of . In particular
.
Direct
sums
In a basis, every vector has exactly
one expression as a combination (Theorem 1.5.1). Read
that for with
the standard basis: ,
and each vector splits into pieces from these lines in
exactly one way. We want the same property for subspaces
that are not lines.
Sums do not always have it. In ,
two different splittings, because the planes
share the -axis
and the -component
can be handed to either side. If we replace by the -axis , then is the only splitting,
since the -piece
must have first two entries . We give this situation
a name.
A sum is direct when every vector in it breaks
into one piece from each subspace in exactly one
way.
Definition
1.7.2 (Direct Sum)
Let be subspaces of a vector space over . The sum is
direct if every vector
can be written in exactly
one way as In that case we write the sum as . We write to mean that
and the sum is direct.
In words: existence of a splitting is automatic,
since that is what membership in the sum means. The
content of “direct” is uniqueness: if
with , then for every
. The symbol does not build a
new space. It is the same subspace , with a
property recorded in the notation. (Chapter 4 builds an
“external” direct sum out of spaces that do not sit
inside a common .)
Examples.
- Standard basis. . More generally,
if is a basis of , then . A splitting is a choice of coefficients, and
Theorem 1.5.1 says
there is exactly one.
- Two splittings of the plane. Let
be the -axis, the -axis, and the line . Then , with the only splitting. Also
:
if , the second entry forces , and then the first
forces .
So , and there is no other choice.
- Polynomials. . If ,
comparing coefficients gives , , .
- Degenerate.
for every subspace : the only possible
-piece
is , so the
-piece of must be .
Nonexample by minimal change.
Replace the -axis
in by the plane . The sum is still
all of , so
existence still holds. What fails is uniqueness, as the
two splittings of above show. So ,
but the sum is not direct. Likewise
upper plus lower triangular matrices give
, but a
diagonal matrix can be put in either summand, so that
sum is not direct.
Checking uniqueness for every vector
looks like a lot of work. For two subspaces it reduces
to one condition you can check in a line.
Theorem
1.7.4 (Direct Sum Criteria for Two
Subspaces)
Let and be subspaces of a
vector space . The
following are equivalent:
- (a) the sum is direct;
- (b) .
If moreover
and are
finite-dimensional, they are also equivalent to
- (c) .
Idea. Uniqueness questions go
through differences. If , then is a single vector
lying in both and
. So “no overlap”
is exactly “no freedom in splitting”. For (c), the
dimension formula says the overcount is , which is exactly when .
Proof.
(a) (b). Suppose
the sum is direct and let .
Then with , , and with , . These are
two splittings of , so by uniqueness their -pieces agree: .
Hence .
(b) (a). Suppose
, and let with and . Then . The left side lies in
and the right
side in , since
both are subspaces. So this common vector lies in ,
which gives and .
Hence every vector of has only one splitting.
(c) (c). Now
let and be finite-dimensional.
By the dimension formula (Theorem 1.7.3), (c)
holds if and only if . A space has dimension exactly when the empty
list is a basis of it, that is, when it equals the span
of the empty list, which is . So (c)
holds if and only if .
This is the everyday test: to show , show
and .
In finite dimension there is a shortcut that avoids
checking
at all: if and ,
then by (c), so by Theorem 1.6.8. Count
instead of check.
Example
(A plane and a line in )
Let and .
Show that , and split into its two pieces.
Solution. From Example (Two planes in ),
, and
since
. If , then , so . Hence .
By Theorem 1.7.4, ,
so by
Theorem 1.6.8.
Therefore .
To split , look for with , that is, . This gives ,
and The -piece is the average of
the entries times ; the -piece is what is left
over.
The same splitting trick, “average with a reflected
copy”, works for functions and matrices.
Example
(Even and odd functions)
Let
be the space of all functions , with and .
Then .
Solution. Both are subspaces by the
Subspace Test (Theorem 1.2.1): the
zero function is even and odd, and the defining
equations are preserved by sums and scalar multiples.
For instance, if , then .
Sum. For any , put and . Then , and , . So .
Intersection. If , then
for every , so and . Hence ,
and
by Theorem 1.7.4.
For example, is the splitting of the exponential
function.
Example
(Symmetric and skew-symmetric matrices)
Let be a field
of characteristic not (for instance or ), and let . In , let be the symmetric matrices and the skew-symmetric ones (Definition 0.9.11).
Then .
Solution. Both are subspaces: , and by
Theorem 0.9.5, and , so the equations survive
sums and scalar multiples.
Since the characteristic is not , we have in , so exists (Definition 0.7.2). For
,
By Theorem 0.9.5, and .
So the first piece is in , the second in , and .
If , then , so . Multiplying by gives . Hence ,
and by Theorem 1.7.4. The
pattern is the same as even plus odd: transpose plays
the role of .
The hypothesis on the characteristic is used twice,
both times to divide by . Exercise (C1: Symmetric Plus Skew over )
shows what goes wrong over .
Quick check. Can two -dimensional subspaces
of form a
direct sum?
Solution. No. If the sum were direct, Theorem 1.7.4 (c)
would give . But , so by Theorem 1.6.7. So
two planes through in always share a
nonzero vector.
Direct sums
of several subspaces
For
subspaces, the tidy condition
has no direct replacement by pairwise intersections; we
will see why in a moment. What does carry over is the
zero vector test, which looks just like linear
independence, and a condition that compares each
subspace with the sum of all the
others.
Theorem
1.7.5 (Direct Sum Criteria for Several
Subspaces)
Let be subspaces of a vector space , and write .
The following are equivalent:
- (a) the sum is direct;
- (b) the only way to
write with is
;
- (c) for
every ,
If moreover each is finite-dimensional
with a basis ,
and is the list
obtained by writing one after another, then (a)–(c)
are also equivalent to
- (d) is a basis of ;
- (e) .
Here is the sum of the subspaces other
than (and if ).
Idea. Condition (b) is uniqueness
for the single vector , and just as for
independence, uniqueness for gives uniqueness
everywhere by taking differences. For (b) (c), a
nontrivial way of writing is the same
thing as a nonzero vector that equals
minus the sum of the other pieces. For (d), a
combination of
groups into one piece per ; independence of each
turns “piece
is ” into
“coefficients are ”. Finally (d) (e) is
count instead of check: always spans , so it is a basis
exactly when its length is right.
Proof.
(a) (b). The
vector has the splitting . If the sum is direct, it has no
other, which is (b).
(b) (a). Assume
(b), and let with . Subtracting and regrouping, where because is a subspace. By
(b), , that is, , for every . Hence every vector of
has only one
splitting.
(c) (c). Assume
(b), fix , and let
. Then for some , and
so with in the -th slot. By (b), every
piece is ;
in particular , so .
(d) (b). Assume
(c), and let with . Fix
. Then The left side lies in , and the right side
lies in since each . By
(c), . As was arbitrary, all
pieces are .
For the rest, assume each is finite-dimensional
with basis , where
. By
Proposition 1.7.2,
spans . In particular is
finite-dimensional.
(b) (d). Since
spans , it remains to prove
independence. Let , and group the
terms by subspace: put . Then , so each by
(b). Since is
independent, for each . Hence is independent, and
so a basis of .
(c) (b). Assume
(d), and let with . Since
spans , write . Then is a combination
of the independent list , so every , and therefore
every .
(d) (e). The list
has length
,
so if it is a basis of , then by Definition 1.6.1.
(e) (d). The list
spans and has length , which
equals by
(e). A spanning list whose length is the dimension is a
basis (Theorem 1.6.4). This
proves the theorem.
For ,
condition (c) reads and , so we recover Theorem 1.7.4. The
criteria (d) and (e) say that bases of the
pieces assemble into a basis of a direct sum, and
dimensions add.
For , the
tempting shortcut is to check only the intersections of
the subspaces two at a time. It does not work.
Warning. Pairwise
intersections do not make
a sum direct. In , take the three
lines (the -axis), (the -axis), and (the line ). Any two of them
meet only in . But writes with nonzero
pieces from ,
, , so (b) fails and is
not direct. Condition (c) sees the
problem: .
The same example breaks another tempting
generalization. For finite sets, is given by inclusion–exclusion, and the
dimension formula looks like its two-set case. For three
subspaces the analogous formula would be For the left side is , and the
right side is . So the formula is
false. The reason is that is not a union: the
dimension of is not determined by the pairwise
intersections. Exercise (C3: Three Subspaces)
gives the correct replacement and a second failure.
Complements
Given a subspace of , can we always find a
subspace with
?
Such a is called
a complement of in . In , the plane of Example (A plane and a line in )
has the complement . In finite dimension, complements always
exist, and the proof is again “basis of the smaller
space, then extend”.
Theorem
1.7.6 (Existence of Complements)
Let be a
finite-dimensional vector space and a subspace of . Then there is a
subspace of with . Every
such satisfies
.
Proof. By Theorem 1.6.7, is finite-dimensional;
let be a basis of (Corollary 1.5.5).
This list is independent in , so by the Basis
Extension Theorem (Theorem 1.6.5) there
are such that is a basis of
. Put , a subspace by Theorem 1.3.1.
By Proposition 1.7.2,
. The list is independent, since a relation
is also a relation
among the basis vectors of , forcing all . So is a basis of . The concatenation of
the bases of and
is a basis of
, so the
sum is direct by Theorem 1.7.5 ((d)
(a)).
Hence .
Finally, if is
any subspace with , then is finite-dimensional
(Theorem 1.6.7), and
Theorem 1.7.4 (c)
gives , as claimed.
The proof made a choice: the vectors that extend the basis. Different
choices give different complements.
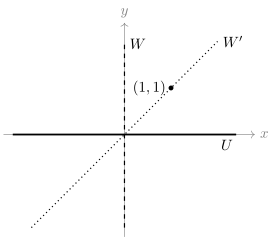
Warning. A complement is
not unique. In , the -axis (solid) has the
complement , the
-axis (dashed),
and also the complement , the line (dotted), as shown
in the examples after Definition 1.7.2. So
“the complement of ” is meaningless, and
does not allow us to
cancel and
conclude . What all complements share is their
dimension. Also, a complement is not the set complement
,
which does not even contain .
Complements matter because a splitting lets us
study one piece
at a time. In Chapter 4 each such splitting gives a
projection of
onto along , and the warning above
becomes visible there: different complements give
different projections. In Chapter 9 the eigenspaces of a
diagonalizable operator split as a direct sum, and
that is what makes such operators easy to
understand.
Exercises
A. Check your
understanding
Exercise
(A1)
- (a) Define the sum
of subspaces of ,
and what it means for the sum to be direct.
- (b) State the
dimension formula for , with its hypotheses.
- (c) True or false:
if and
, then . Justify
your answer.
- (d) True or false:
if
are subspaces with for all , then the sum
is
direct. Justify your answer.
- (e) True or false:
if is a subspace
of with , then is a
complement of .
Justify your answer.
- (f) Name the method
used to prove the dimension formula, in four steps.
Solution.
(a) See Definition 1.7.1:
. By Definition 1.7.2,
the sum is direct if every vector in it can be written
as with in
exactly one way.
(b) If and are finite-dimensional
subspaces of a vector space , then (Theorem 1.7.3).
(c) True. By Theorem 1.7.4,
means the sum
is direct, and it equals .
(d) False. The
three lines ,
, in (the axes and the
line ) meet
pairwise only in , but is a nontrivial way to write , so the sum is
not direct by Theorem 1.7.5.
(e) False. does not
contain ,
because . So it is not a subspace, and cannot be a
complement.
(f) Take a basis
of the smallest space ; extend it to bases of and of (Basis Extension);
prove the Big Claim that all the vectors together form a
basis of
(spanning, then independence by moving one block across
and noting the common vector lies in );
count.
B. Practice
Exercise
(B1: Two Planes in )
Let and in .
- (a) Show that .
- (b) Find and its
dimension.
- (c) Hence find and a basis
of .
Solution.
(a) If , then and from the first and
third entries. So the spanning list of is independent, hence a
basis, and . Similarly forces , then , so .
(b) A vector lies
in exactly
when for some . The
first entries give . The second gives , so . The third gives
, so ; the fourth, , then holds. So
the common vectors are , and , of dimension .
(c) By the
dimension formula (Theorem 1.7.3),
. Following its proof: is a list in (by (b), ). It is independent by Lemma 1.5.3, since a
multiple with first entry is . It has length , hence it is a basis of by Theorem 1.6.4.
Likewise is a basis of . By the Big Claim in
the proof, is a basis of .
Exercise
(B2: A Plane and a Line)
Let and .
- (a) Prove that .
- (b) Write as with
and
.
Solution.
(a) Solving for
, every vector of
is . These two vectors are independent
(look at the second and third entries), so . Since ,
. If
,
then , so ; hence . By Theorem 1.7.4, ,
so by
Theorem 1.6.8.
Therefore .
(b) We need with , that is, . This gives . So and indeed , so . By (a) this is the only such
splitting.
Exercise
(B3: Direct or Not?)
Determine which of the following sums are direct.
Justify your answer.
- (a) in .
- (b) in , where and are the
upper and lower triangular matrices.
- (c) in .
- (d) in .
Solution.
(a) Direct. If
, then .
Comparing coefficients of gives , so . By Theorem 1.7.4 the
sum is direct.
(b) Not direct.
The identity matrix is both upper and
lower triangular, so , and Theorem 1.7.4
applies.
(c) Direct. Each
line has the basis given by its spanning vector, and we
check that the concatenated list is independent. If , then , hence and . The list spans the
sum by Proposition 1.7.2,
so it is a basis of the sum, and the sum is direct by Theorem 1.7.5 ((d)
(a)).
(d) Not direct,
although any two of the three lines meet only in (no spanning
vector is a multiple of another). Indeed writes as a sum of
nonzero pieces from the three lines, so
condition (b) of Theorem 1.7.5
fails.
C. Going deeper
Exercise
(C1: Symmetric Plus Skew over )
Let and
be the
symmetric and skew-symmetric matrices in .
Solution.
(a) In we have , so for every , and hence
for every
.
Therefore holds if and only if , which says
.
(b) By (a), , which
contains . So the sum is not direct (Theorem 1.7.4). It
is not even all of : , and is not symmetric. In Example (Symmetric and skew-symmetric matrices)
both halves of the proof divide by : the splitting and the step from to . In , has no
inverse, so neither step is available. This is exactly
the case of characteristic excluded by the
hypothesis.
Exercise
(C2: Subspaces That Must Meet)
- (a) Let be a vector space of
dimension , and
let , be subspaces with .
Prove that .
- (b) Deduce that any
two -dimensional
subspaces of contain a common nonzero polynomial.
- (c) Give an example
showing that (a) fails if “” is replaced by
“”.
Solution.
(a) By Theorem 1.6.7, , , and are
finite-dimensional, and . By the dimension formula (Theorem 1.7.3),
A subspace of positive dimension has a basis
with at least one vector, which is nonzero because a
list containing is dependent.
Hence .
(b)
and . By (a), the two subspaces meet in a nonzero
polynomial.
(c) In (with ), the -axis and the -axis have , but their
intersection is .
Exercise
(C3: Three Subspaces)
- (a) Let be
subspaces of a vector space . Show that .
- (b) Now let be
finite-dimensional. Prove that
- (c) In , let , , and
.
Compute , every , and
. Show that the inclusion–exclusion formula
fails, and compare with (b).
Hint: for (b), apply the dimension formula
twice.
Solution.
(a) Both sides
are subspaces by Theorem 1.7.1. The
right side contains and , hence (Theorem 1.7.1), and
it contains ; so
it contains by Theorem 1.7.1.
Conversely, an element of the right side is the sum of
and , so it
lies in the left side.
(b) By Theorem 1.7.3, is
finite-dimensional with . Applying the formula
again to
and , and using
(a), Substituting the first equation into the
second gives the formula.
(c) Each is a plane, so : , , , each with an evidently
independent spanning list. All three contain the -axis .
- .
- .
- .
- .
So each of these has dimension . Since contains , it is , and so
has dimension .
The inclusion–exclusion formula would give so it fails. In (b), the last term is , of dimension , and indeed .
The inclusion–exclusion guess replaces this by , which is wrong because is
much bigger than .